

For Allegro Hand V4 Flat
by WONIK Robotics
1,248 measurements with minimal wiring.
Designed for the Allegro Hand V4 by Wonik Robotics, this fully sensorized hand uses flat uSkin sensors across all fingers, thumb, and palm, providing complete tactile coverage in a soft, protective skin. The microcontrollers are encapsulated and mounted to the back of the fingers and the inside of the palm. The integration comes with all required parts, and users can choose which part of the hand to cover with sensors. Only one cable with four wires is required for each finger, and two cables for the whole hand (two CAN bus cables).
Specifications
Type of sensor
uSkin Patch (flat)
Sensing points per fingertip
16
Sensing points per phalange
16
Sensing points palm
72
Total sensing points
4 fingertips × 16 + 11 phalanges × 16 + 72 (palm) = 312
Measurements per sensing point
4 (3-axis touch and internal temperature)
Total number of measurements
312 × 4 = 1,248
Sensors connect directly to uAi Software for visualization, calibration, and compensation, providing consistent tactile data across diverse applications.
Compact Sensing Points

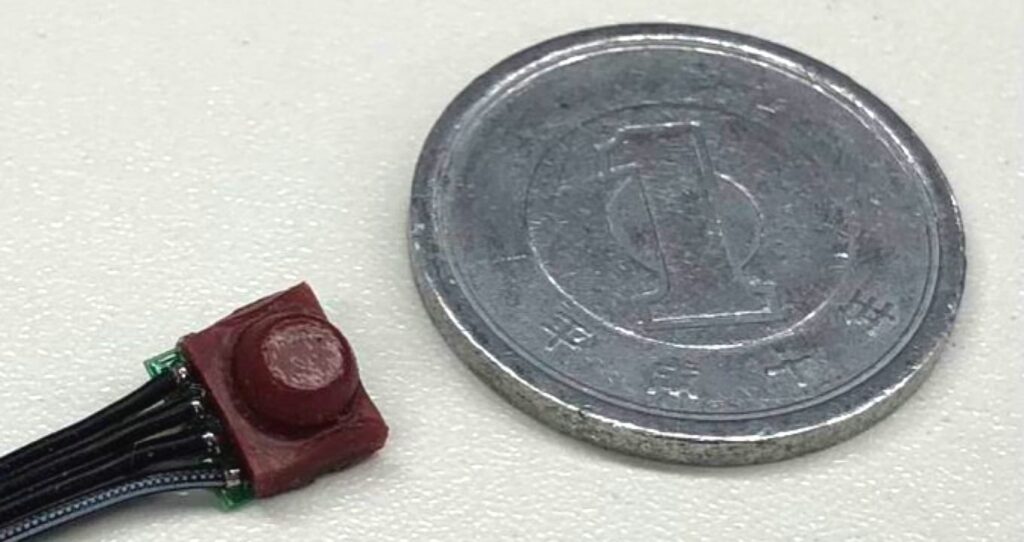
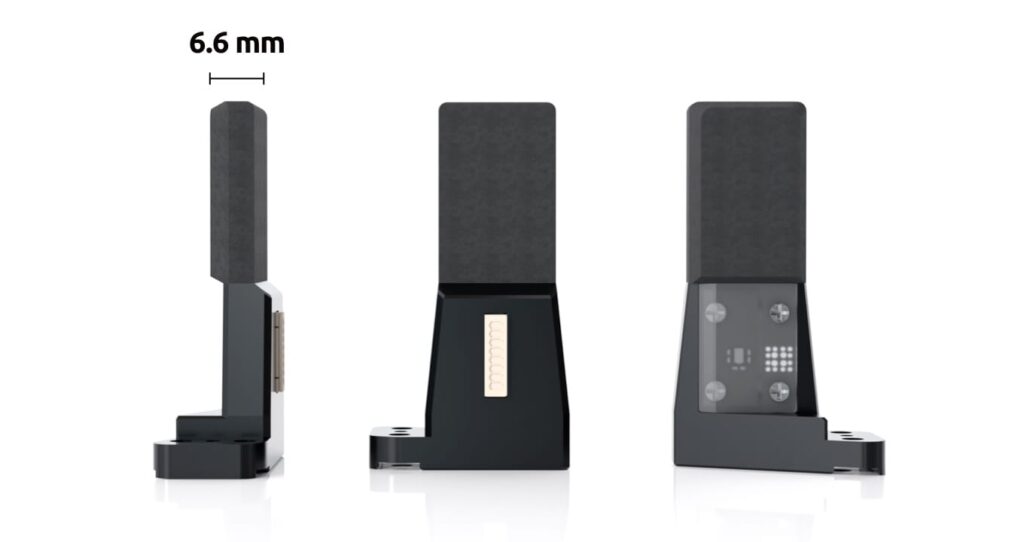
Distributed 3-axis Sensing
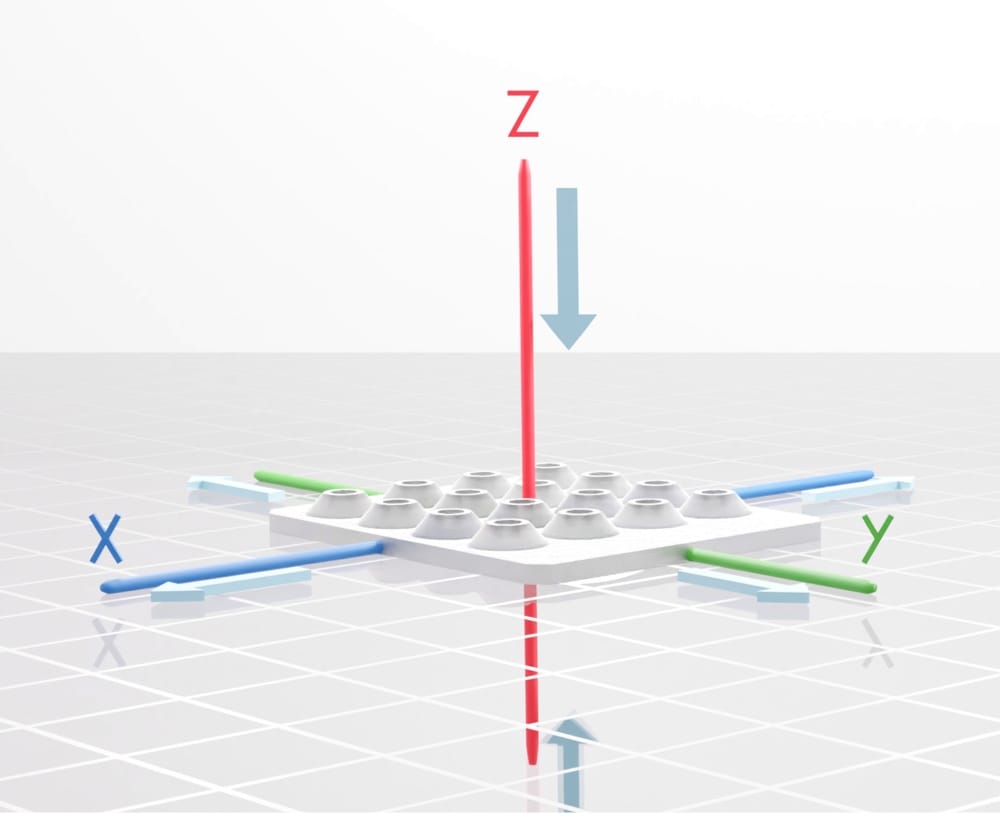
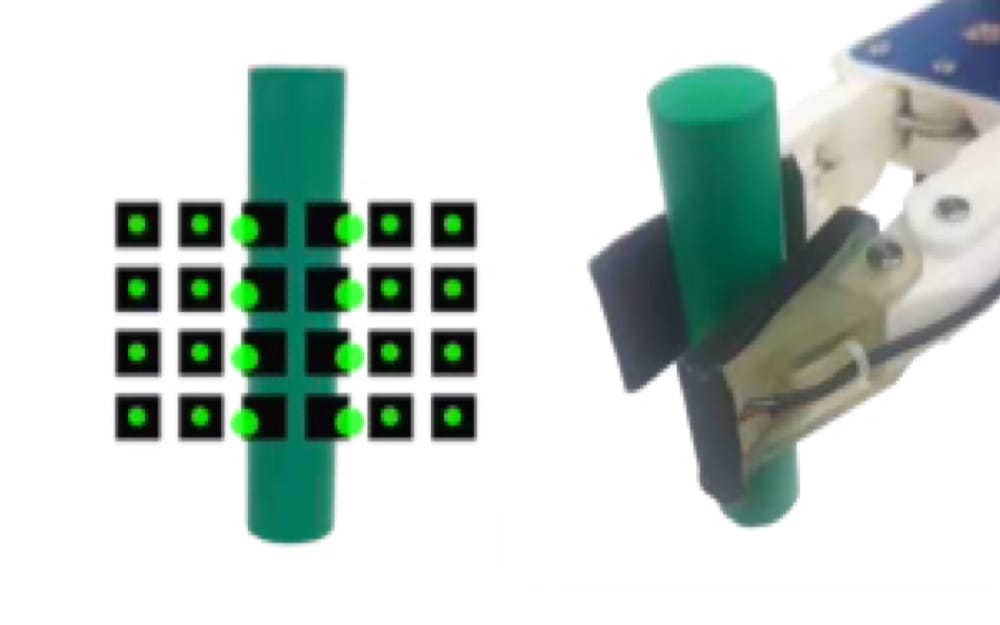
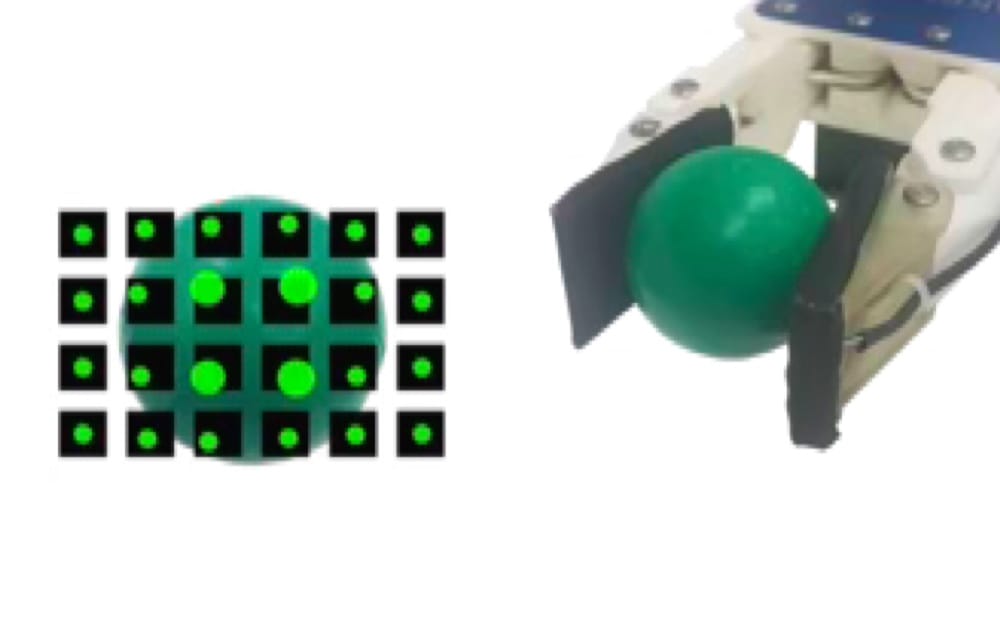
Sensitive: 0.1 gram-force Resolution
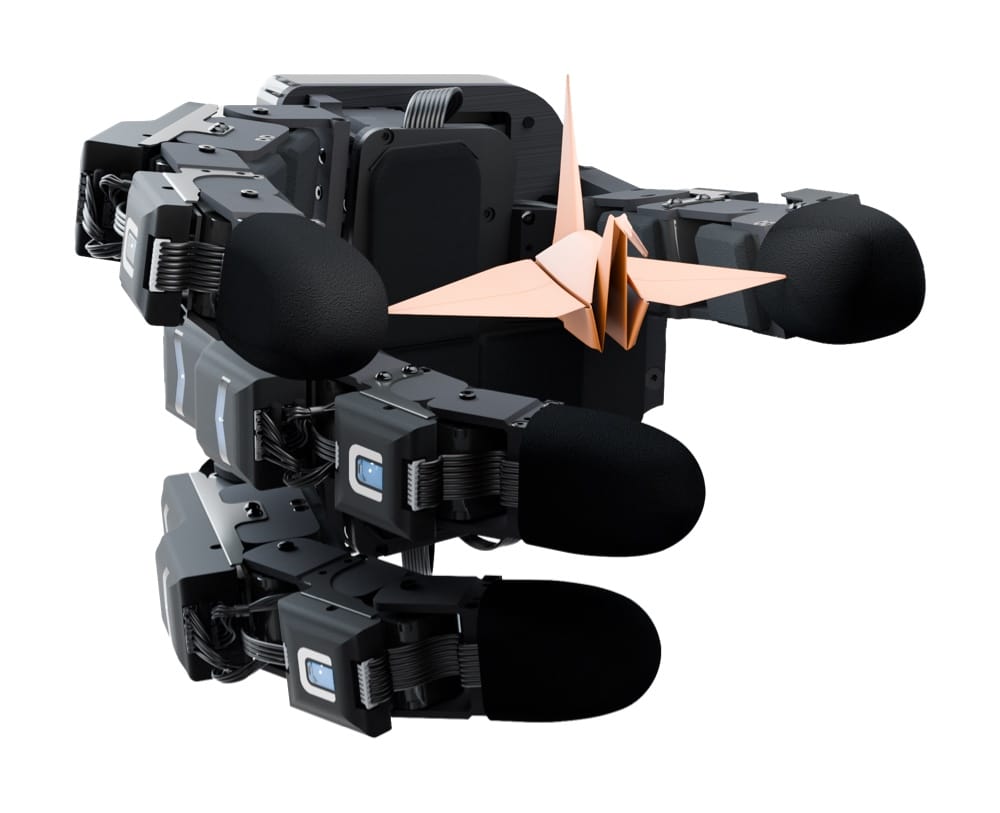
Soft & Robust
Minimal Wiring & Fast Sampling: 500 Hz
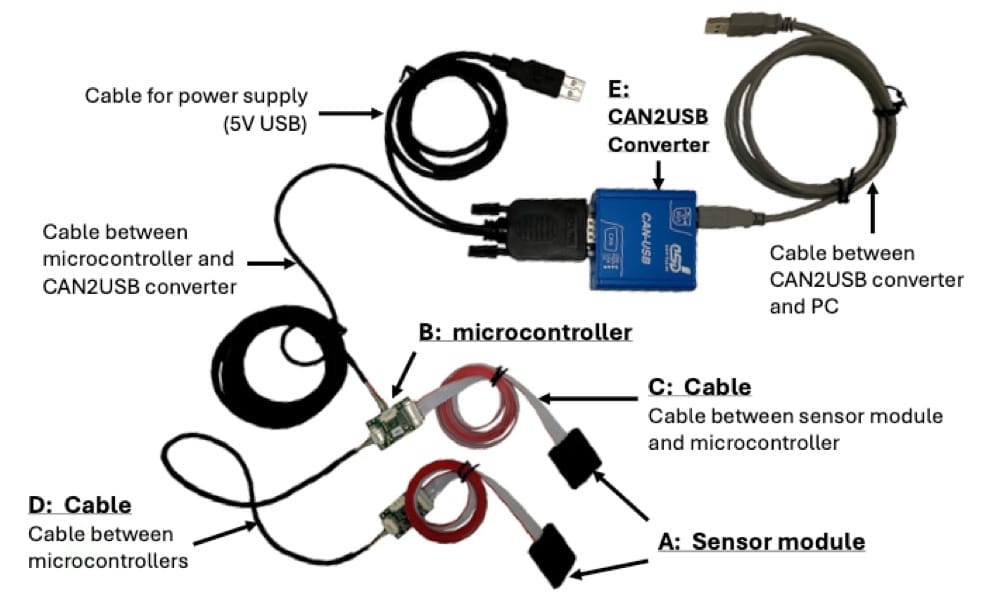
Easy to Integrate & Use
Calibrated in Newtons
Temperature & Magnetic Compensation
Process, visualize, and analyze tactile data with uAi software
XELA’s software platform for processing tactile data from uSkin sensors.