Customization
Every Robot is Different.
XELA offers flexible sensor design and integration services to match your robot’s geometry, wiring, and tactile requirements.
From adapting standard uSkin sensor modules to developing new sensor layouts, our engineering team supports both research and industrial applications.
Customization options example
uSkin® sensor’s shape, size, and curvature
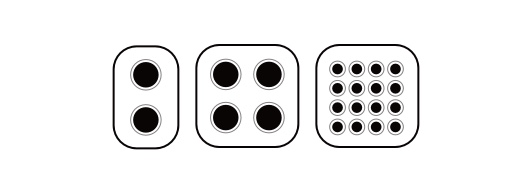
Sensing point arrangement and density
Protective casing or encapsulation
Different outer layer materials available for different use cases
Hardware-agnostic by design
We provide full integration support for robotic hands and grippers
Our goal is to make tactile sensing practical for any robot, regardless of its design. uSkin adapts to the hand, not the other way around.
Send us the CAD of your end effector and we will assess what a uSkin integration would look like on your hardware.
We integrate uSkin into parallel and three-finger grippers, multi-finger robotic hands, and bespoke or in-development end effectors, covering fingertips, phalanges, palms, and other contact surfaces. Compact modules and conformable sensing surfaces mean integration rarely requires redesigning the hand around the sensor.
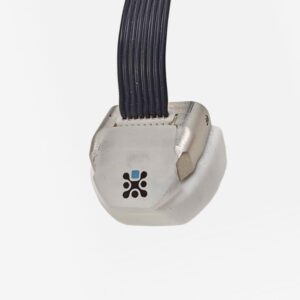
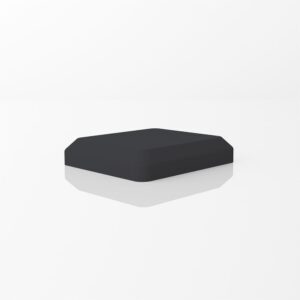
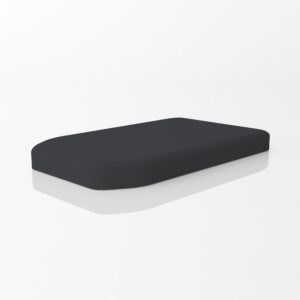
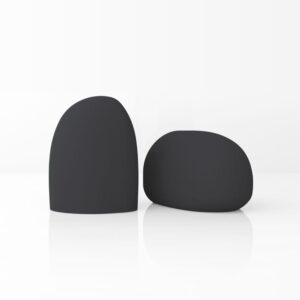
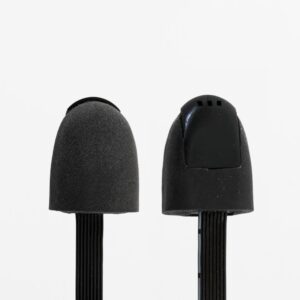
Don’t see your model listed? We can build a custom fit.
XELA offers flexible sensor design and integration services to match your robot’s geometry, wiring, and tactile requirements.