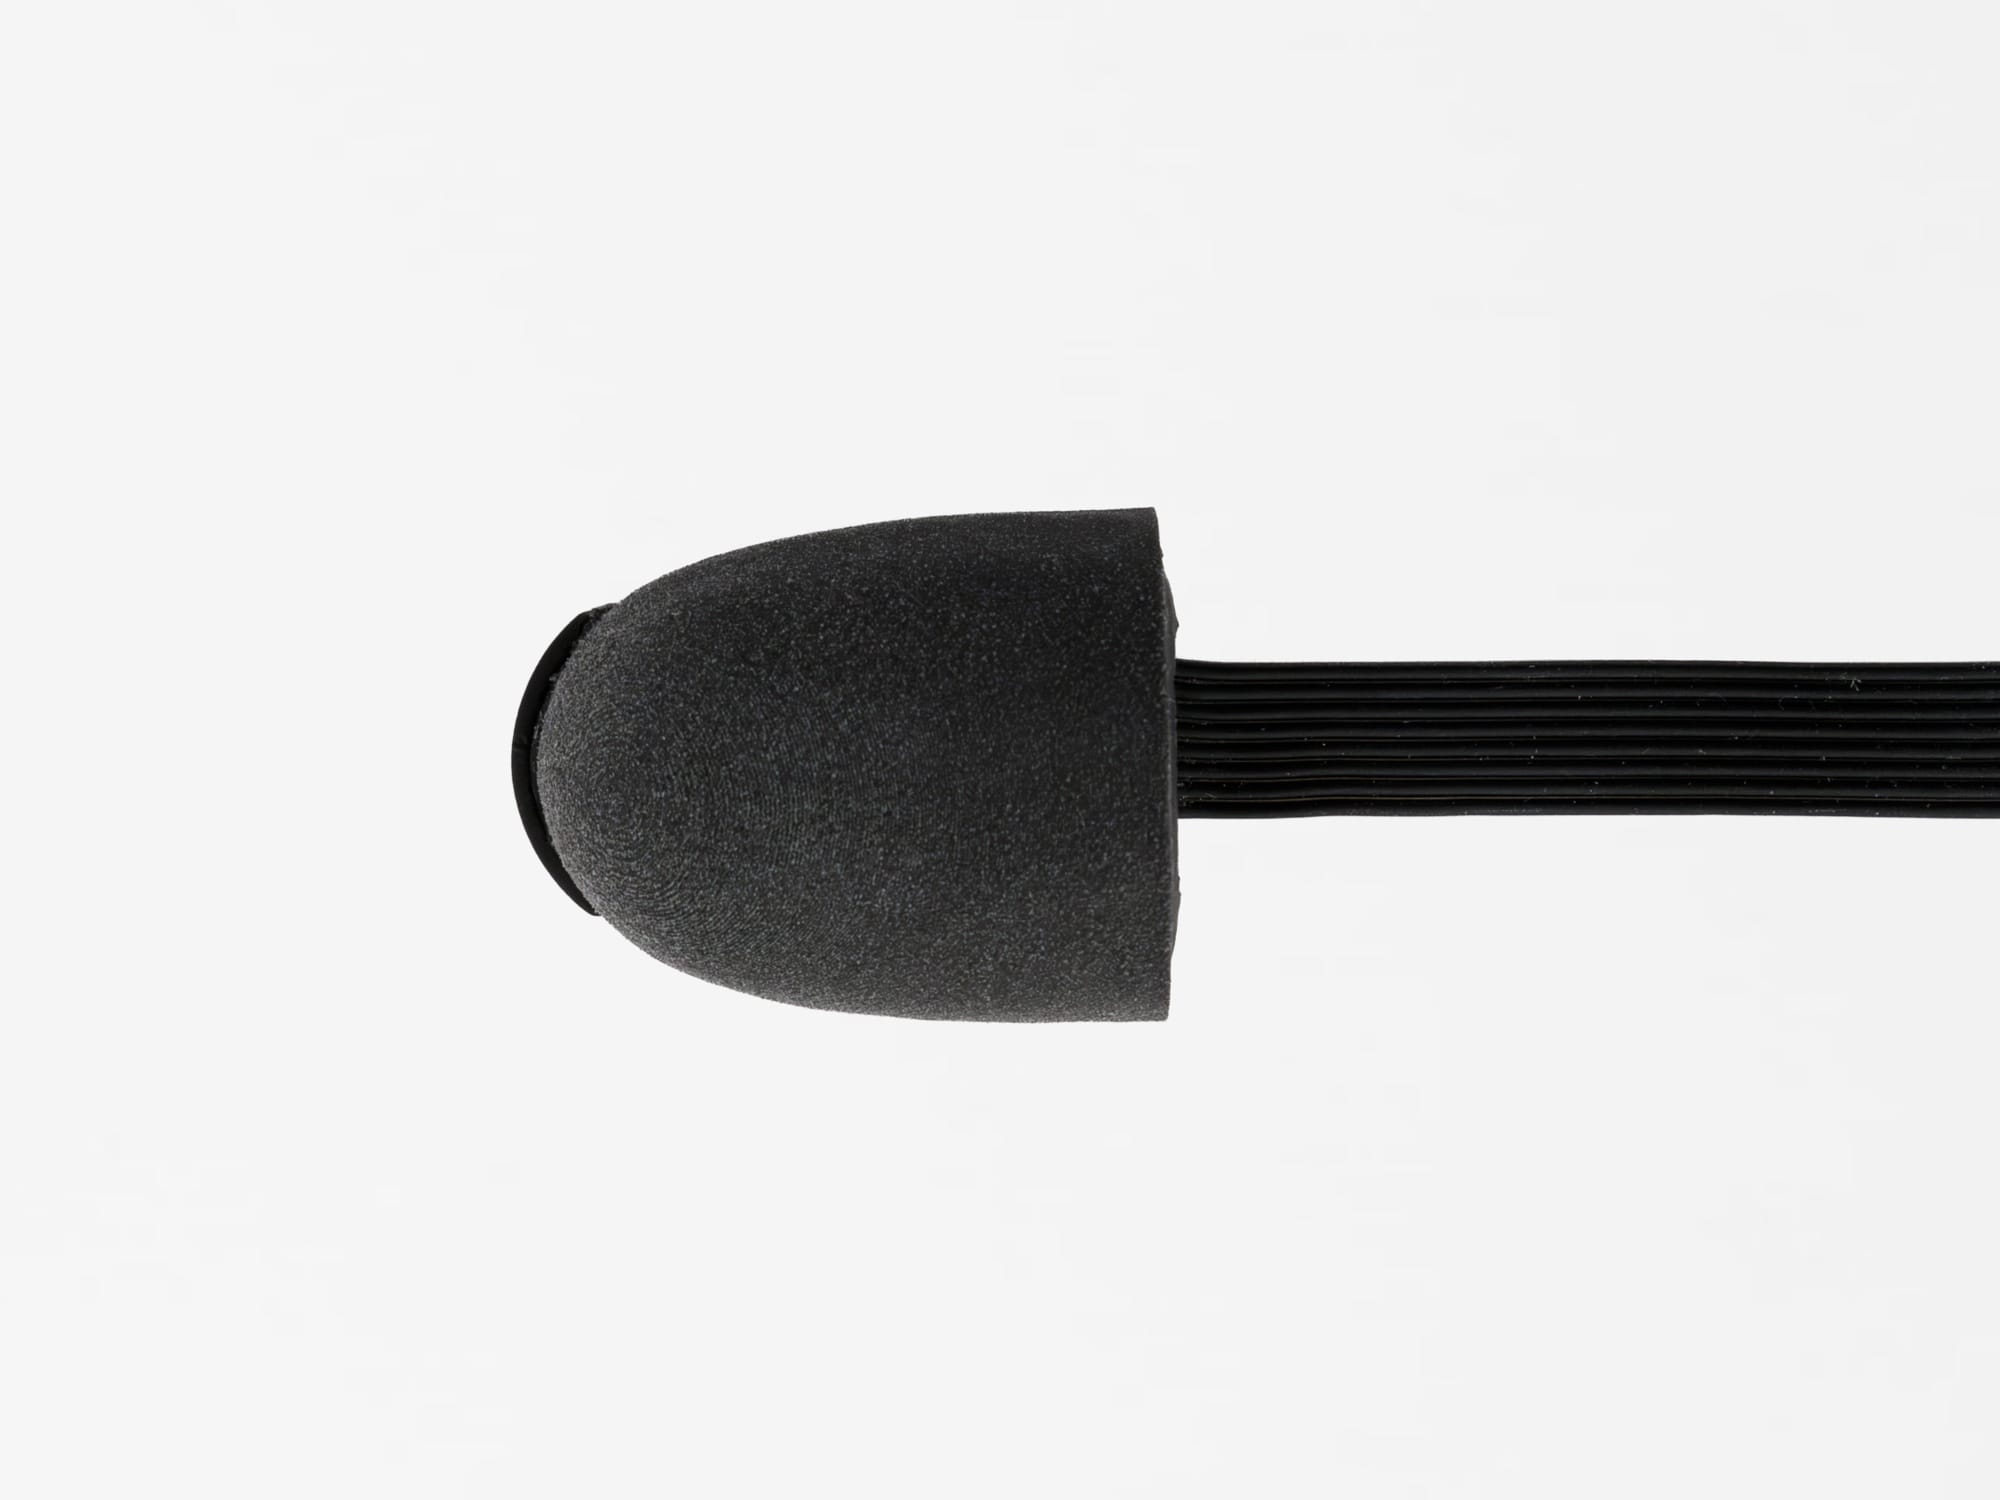

uSCu ALHA-N
Designed for the Allegro Hand
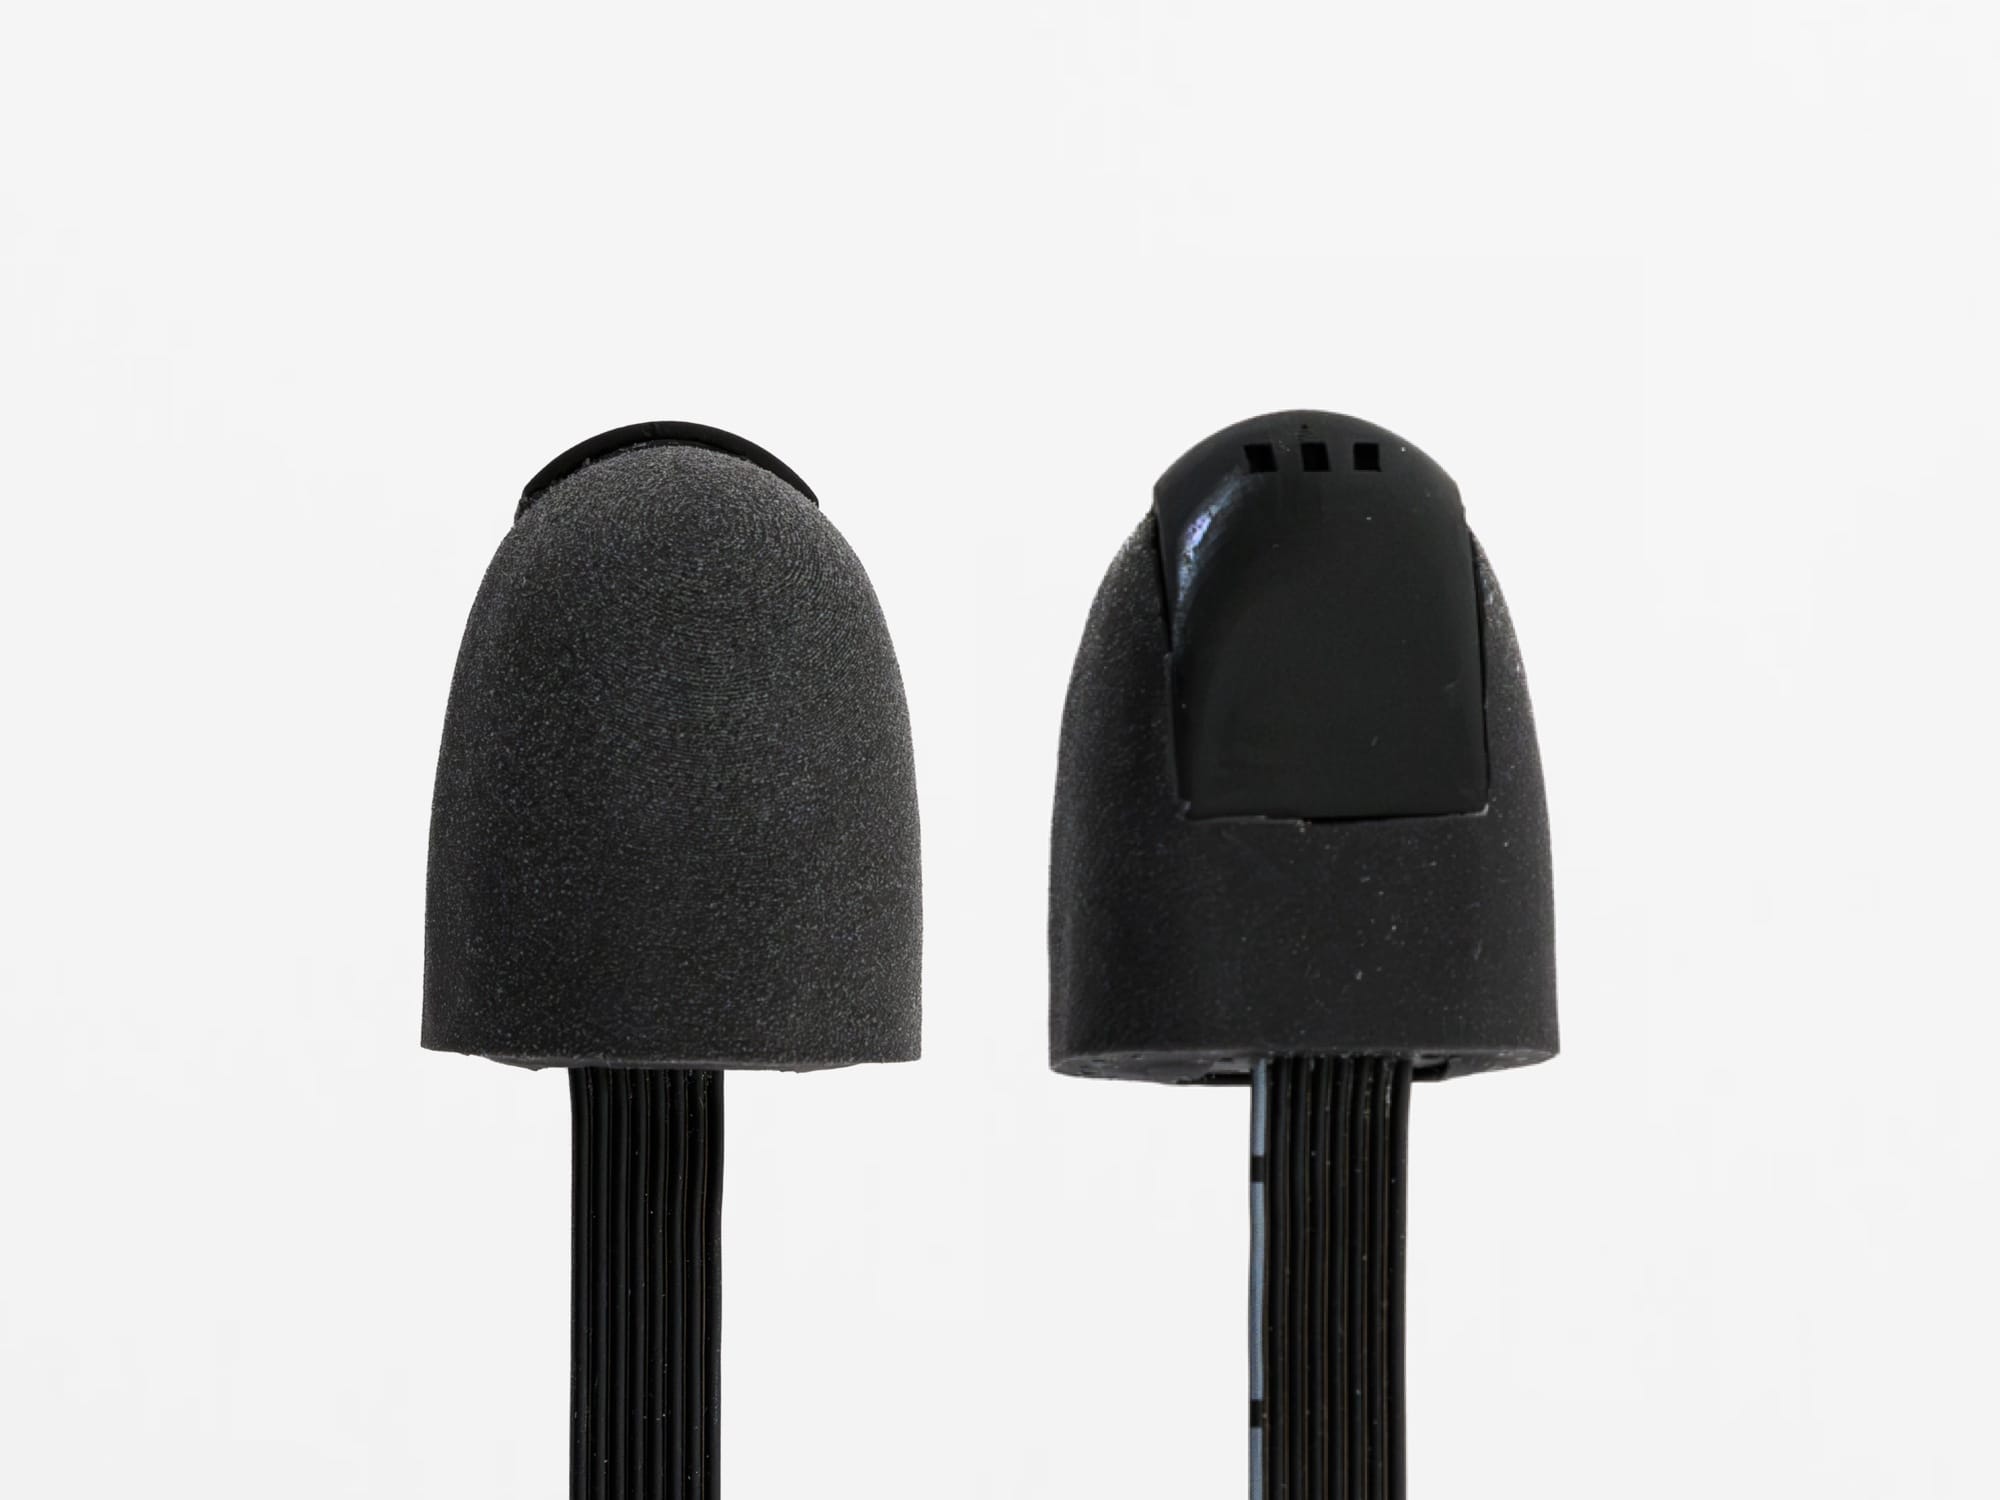
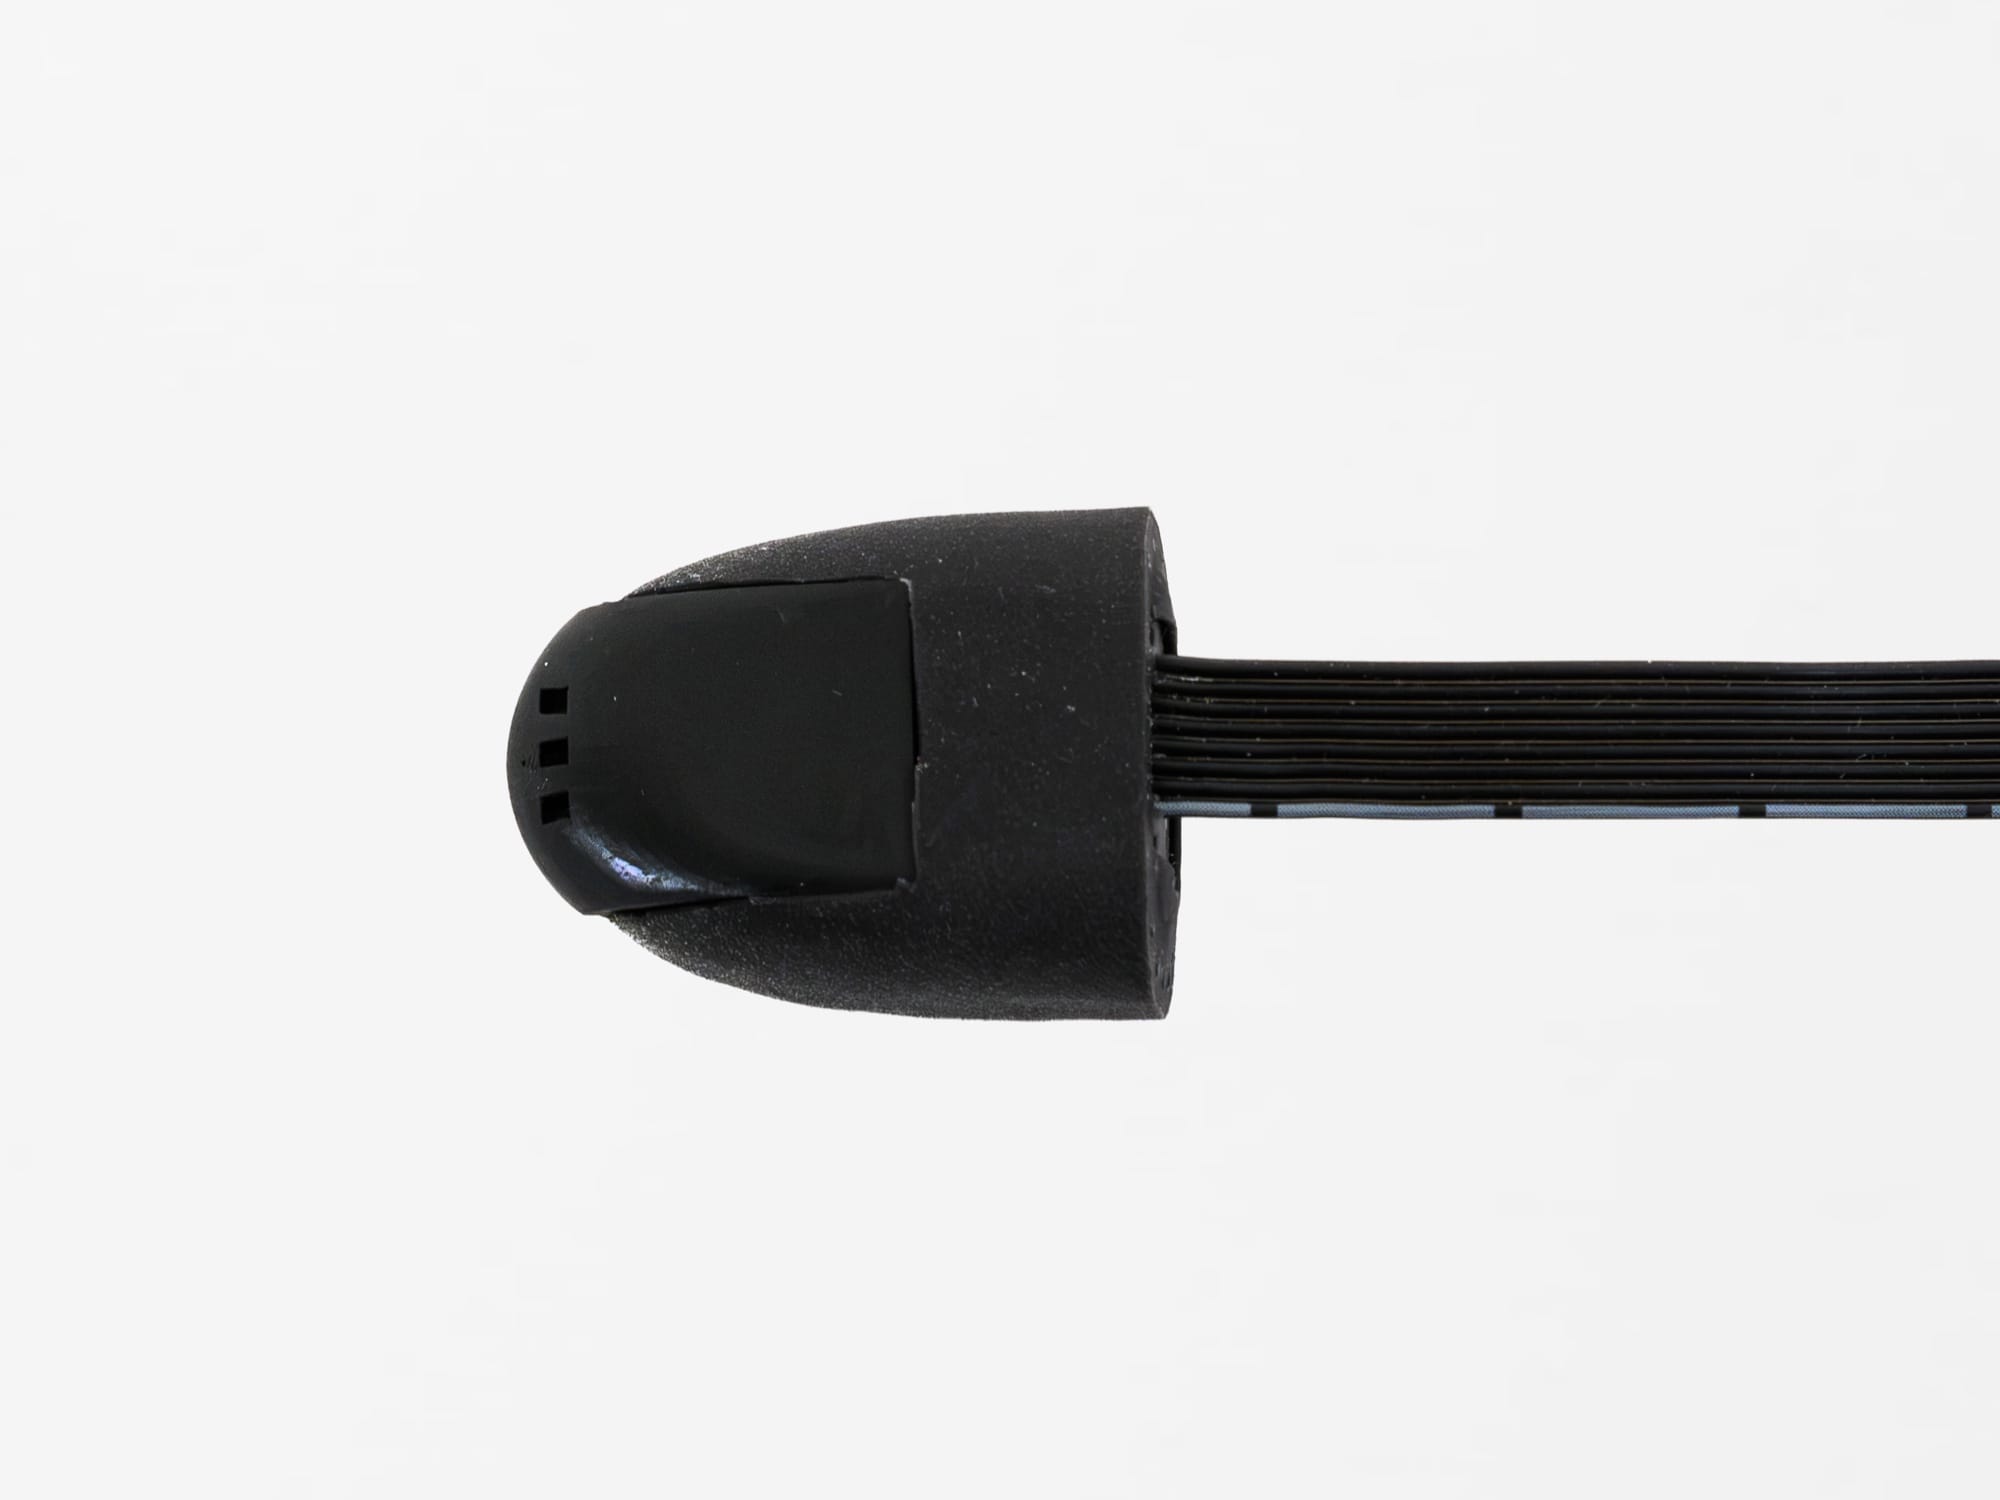
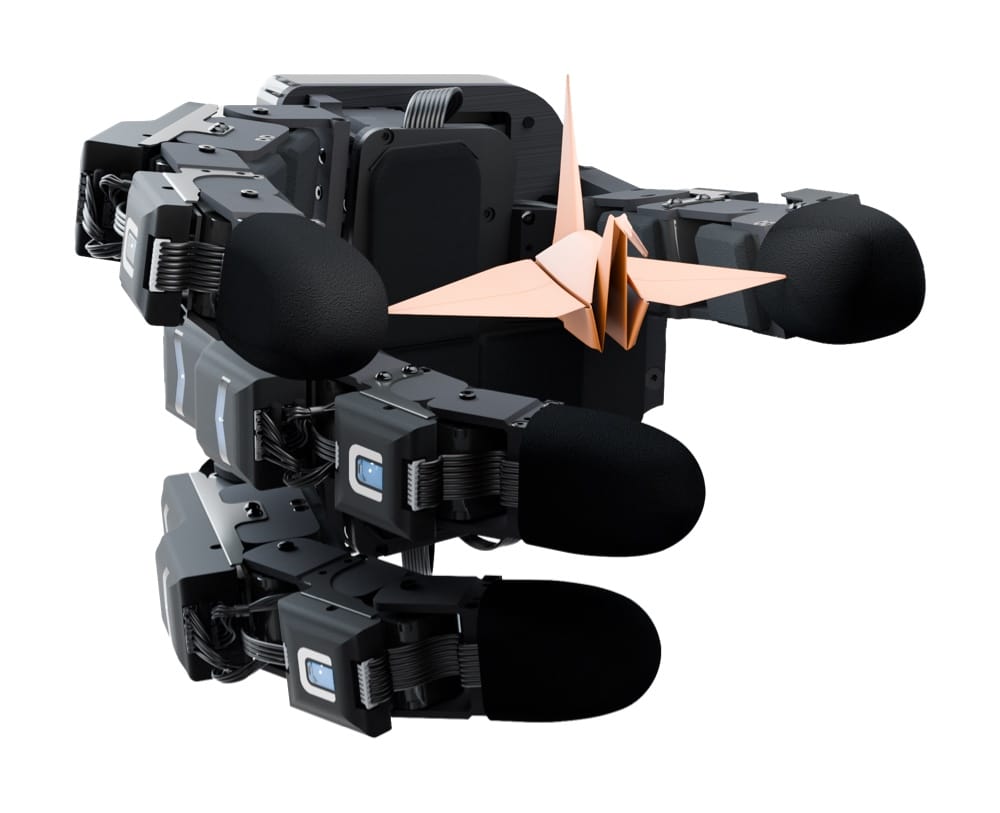
The curved fingertip design of the uSCu ALHA-N enables more natural object interaction, especially with flat objects. This particular version integrates a six-axis, force-sensitive nail, as well as 30 3-axis force sensing points distributed in the pulp. This particular sensor is specifically designed for integration into the Allegro Hand by Wonik Robotics.
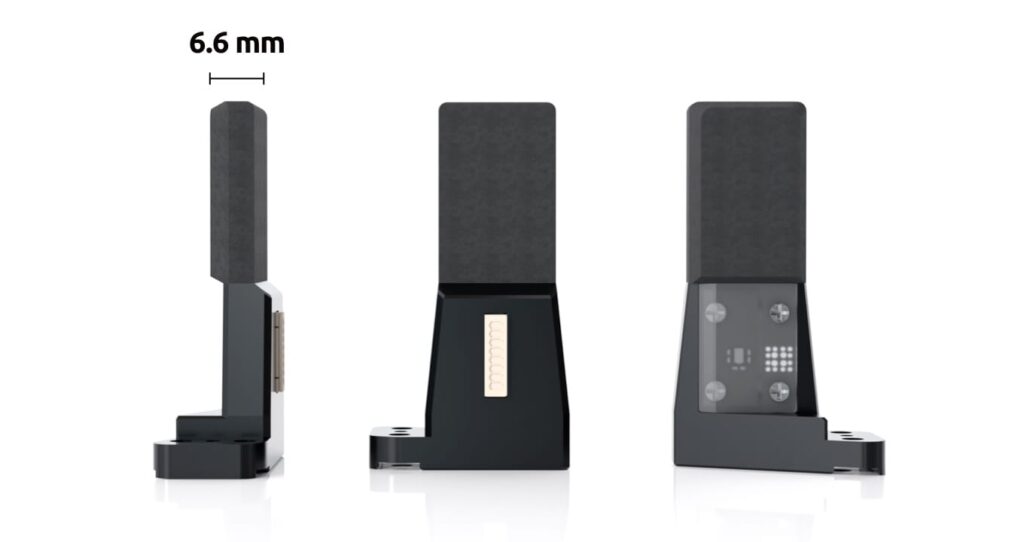
The corresponding microcontrollers are encapsulated and can be mounted to the back of the fingers. The robotic nail complements the tactile sensors in the fingertip to enable the dexterous grasping of extremely thin objects, including thin cards and keys, and the conducting of actions as complex as scraping tape off a surface.
Specifications
Type of sensor
uSkin Curved
Product code
uSCu ALHA-N
Sensing points per fingertip
33 (30 in the pulp and 3 in the nail)
Maximum sensing frequency
275 Hz
Sensors connect directly to uAi Software for visualization, calibration, and compensation, providing consistent tactile data across diverse applications.
Compact Sensing Points

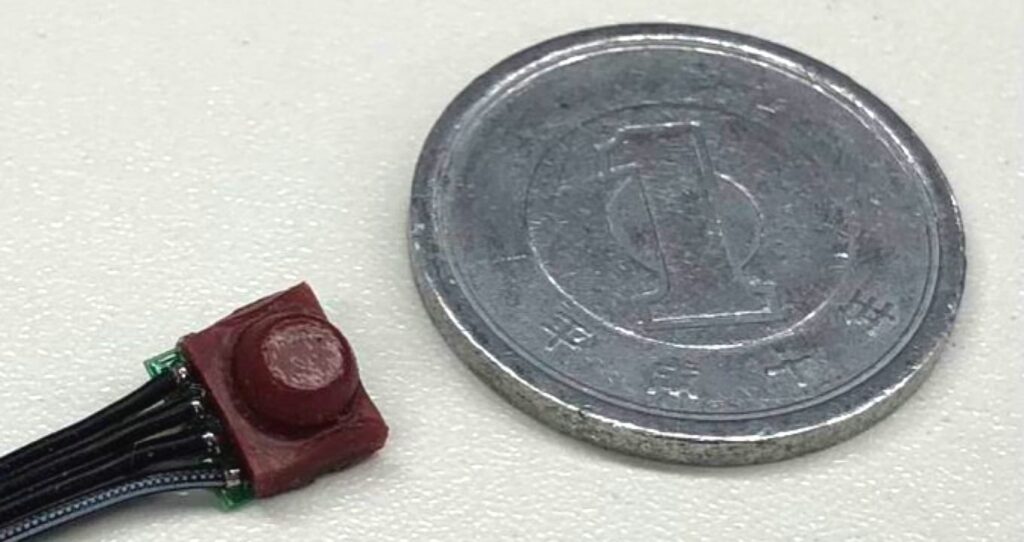
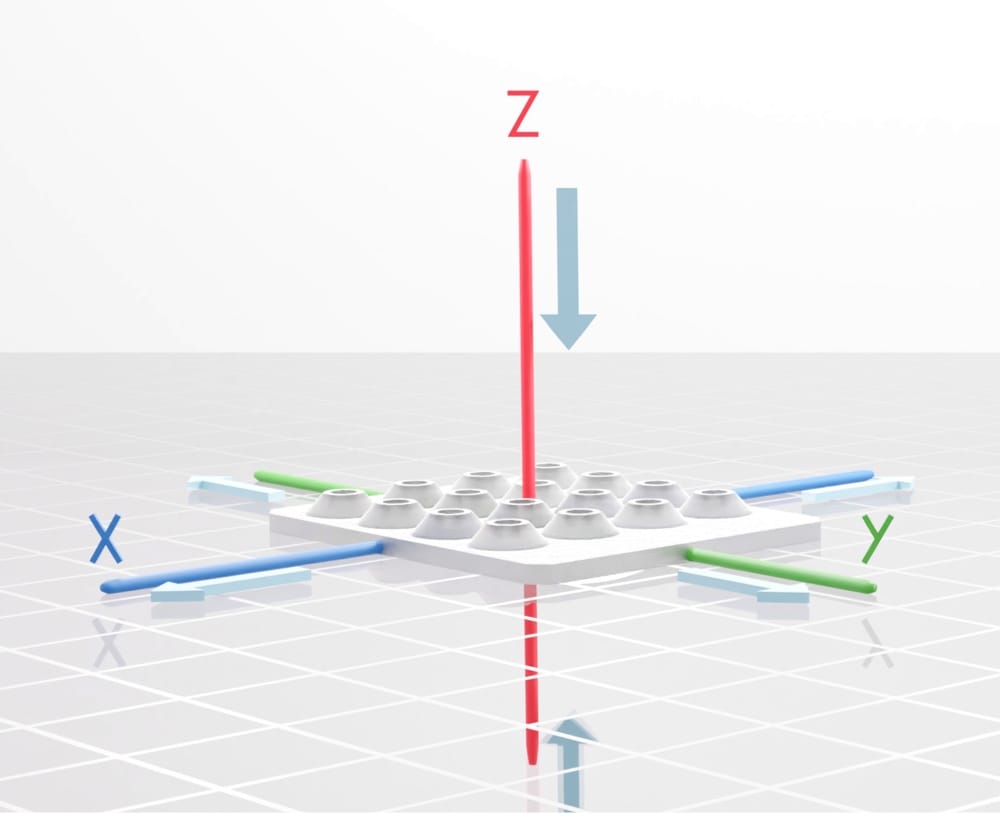
Distributed 3-axis Sensing
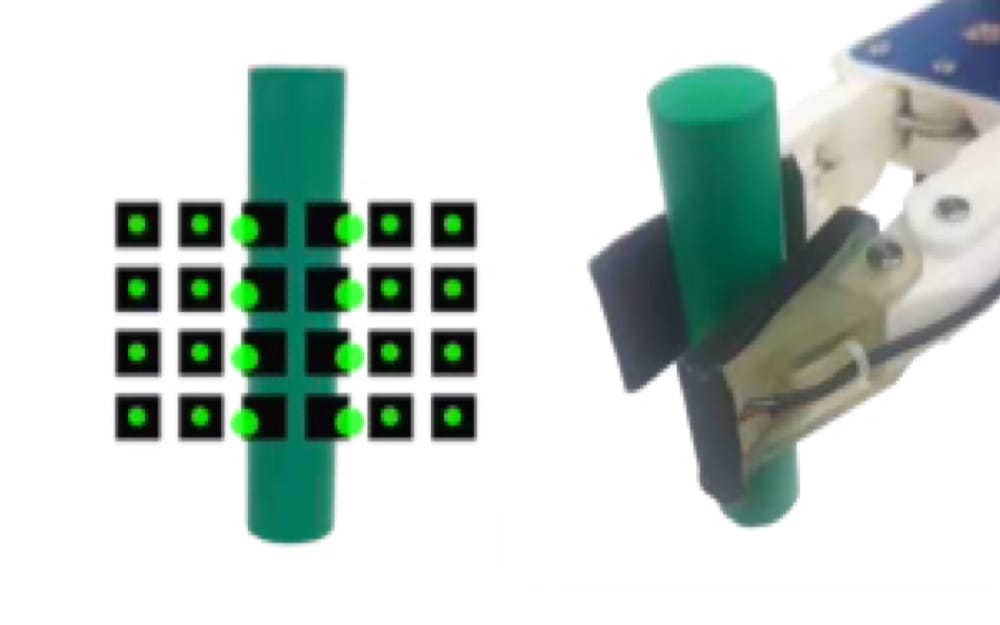
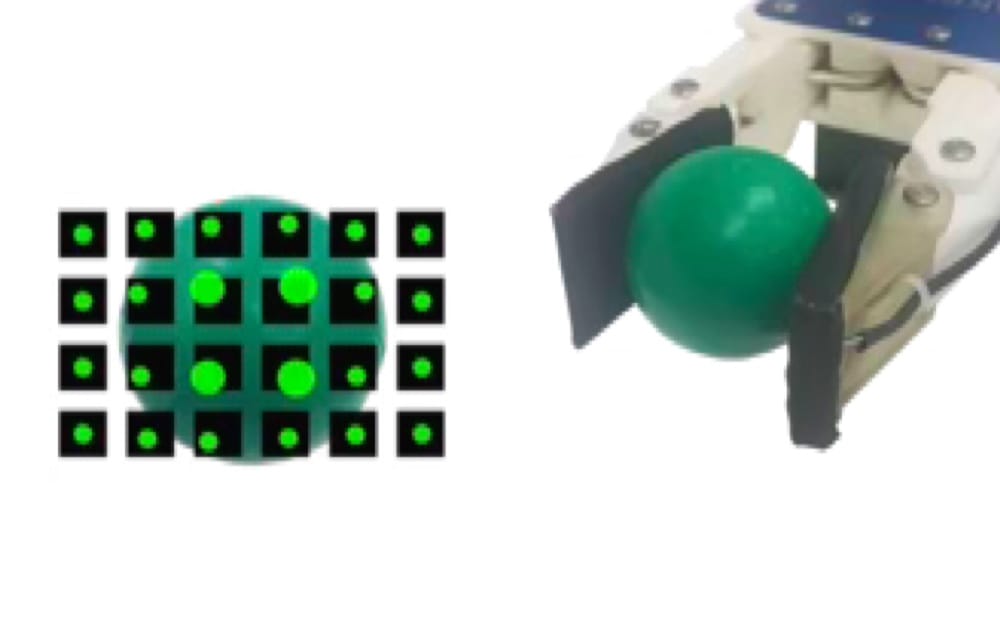
Sensitive: 0.1 gram-force Resolution
Soft & Robust
Minimal Wiring & Fast Sampling: 500 Hz
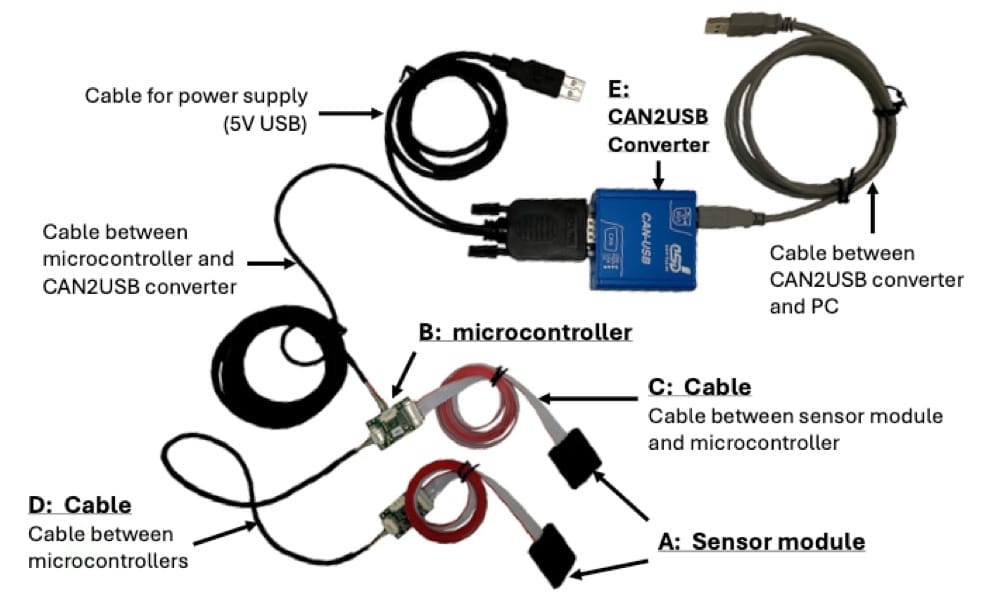
Easy to Integrate & Use
Calibrated in Newtons
Temperature & Magnetic Compensation
Process, visualize, and analyze tactile data with uAi software
XELA’s software platform for processing tactile data from uSkin sensors.