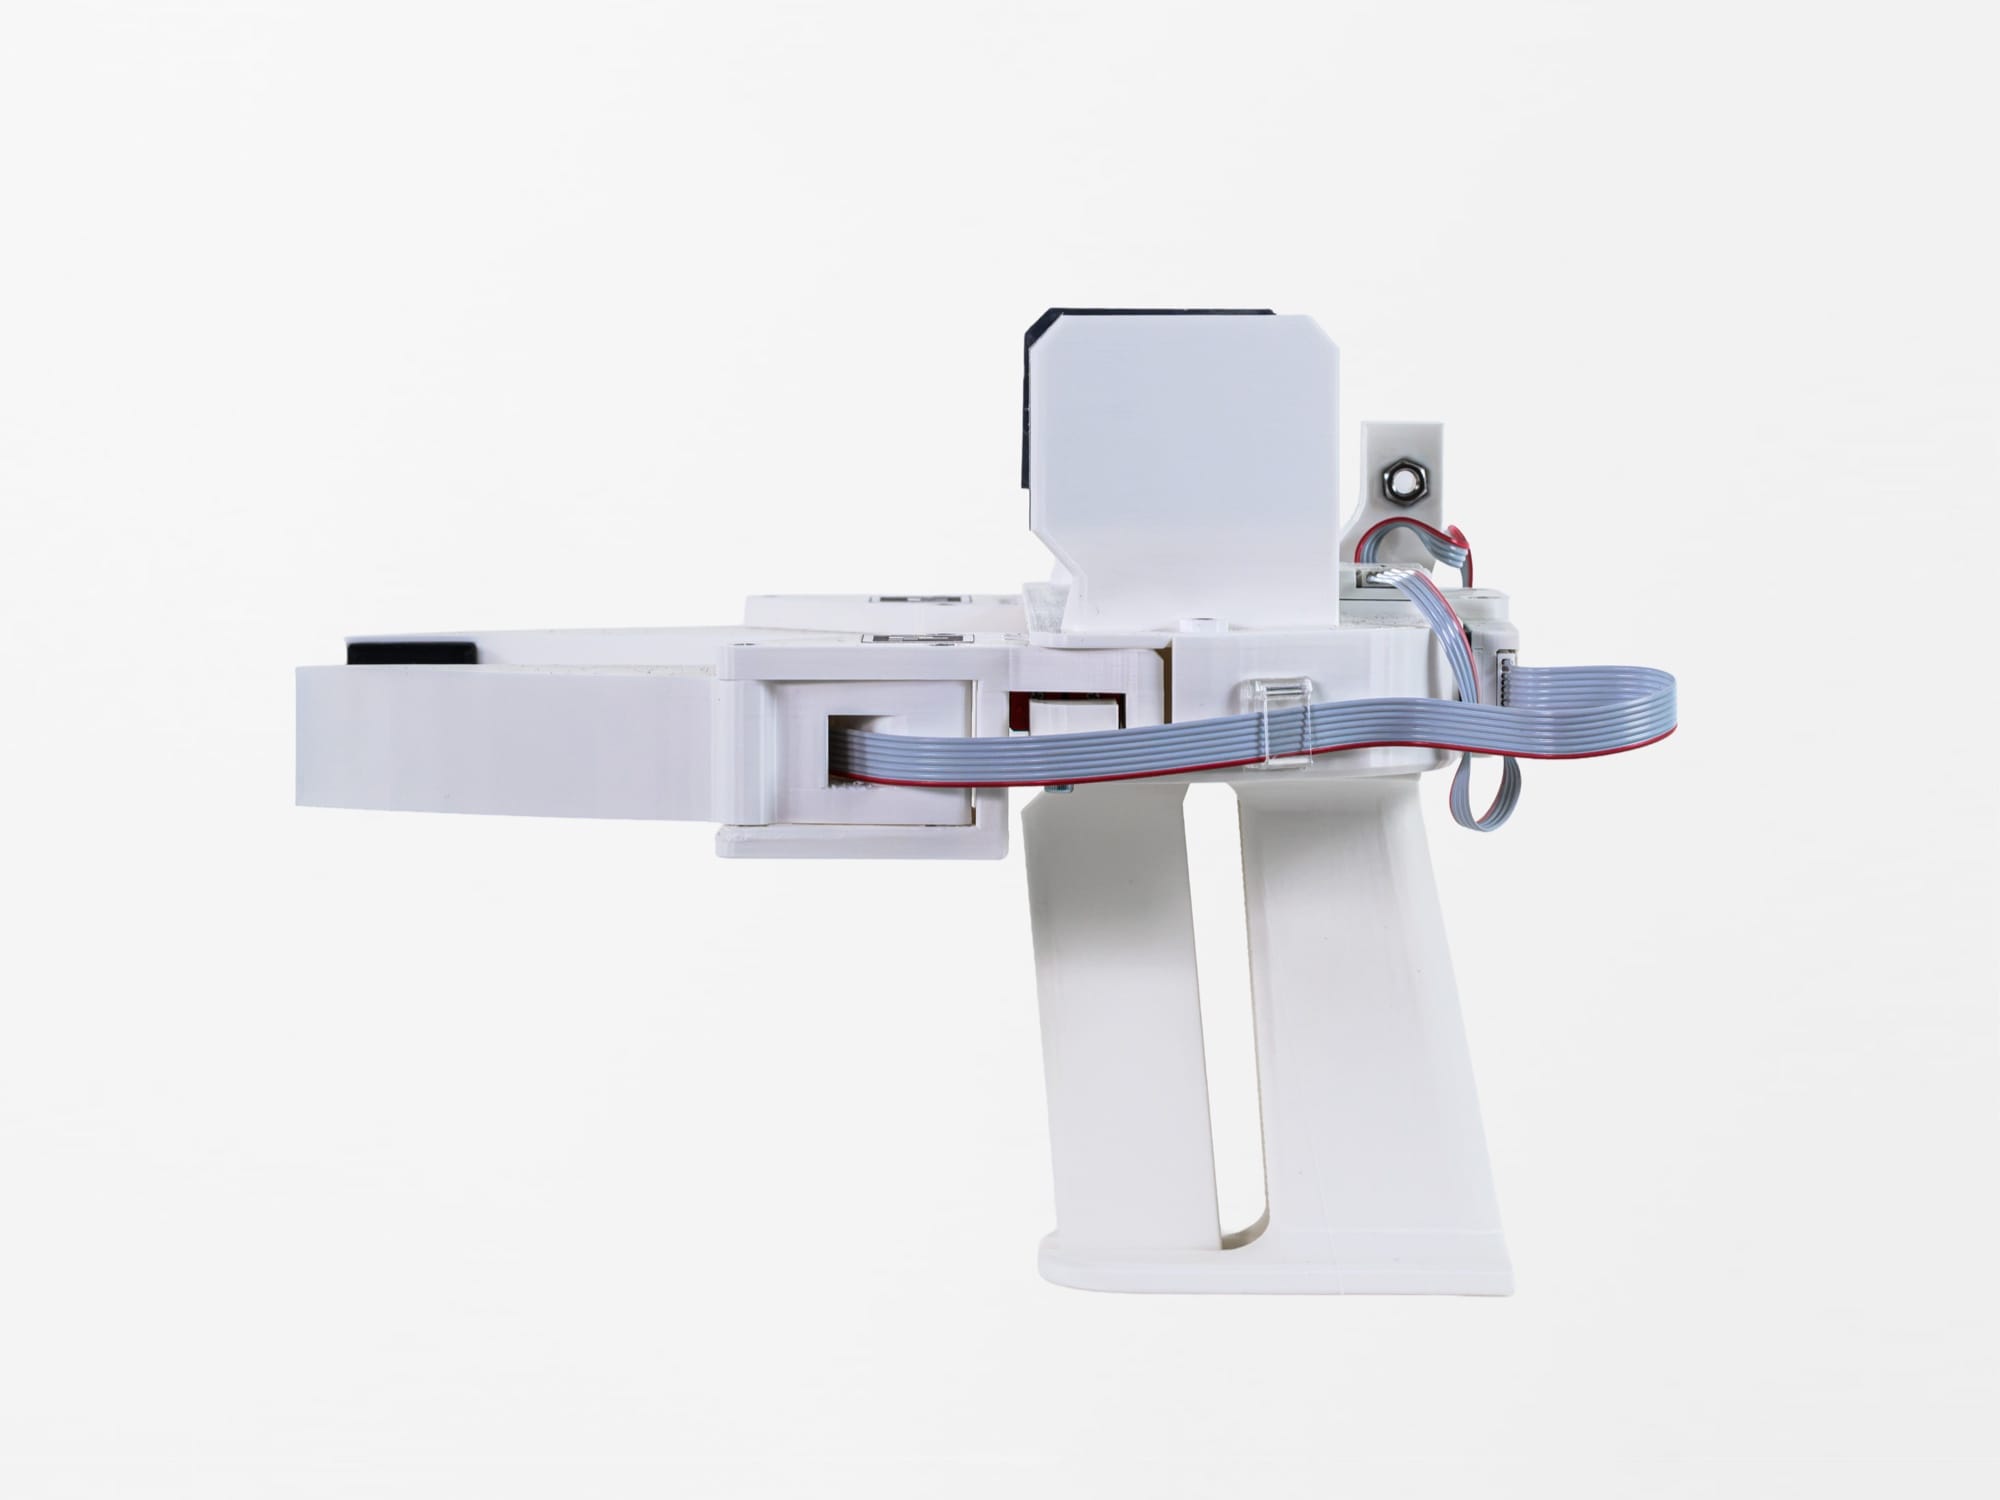
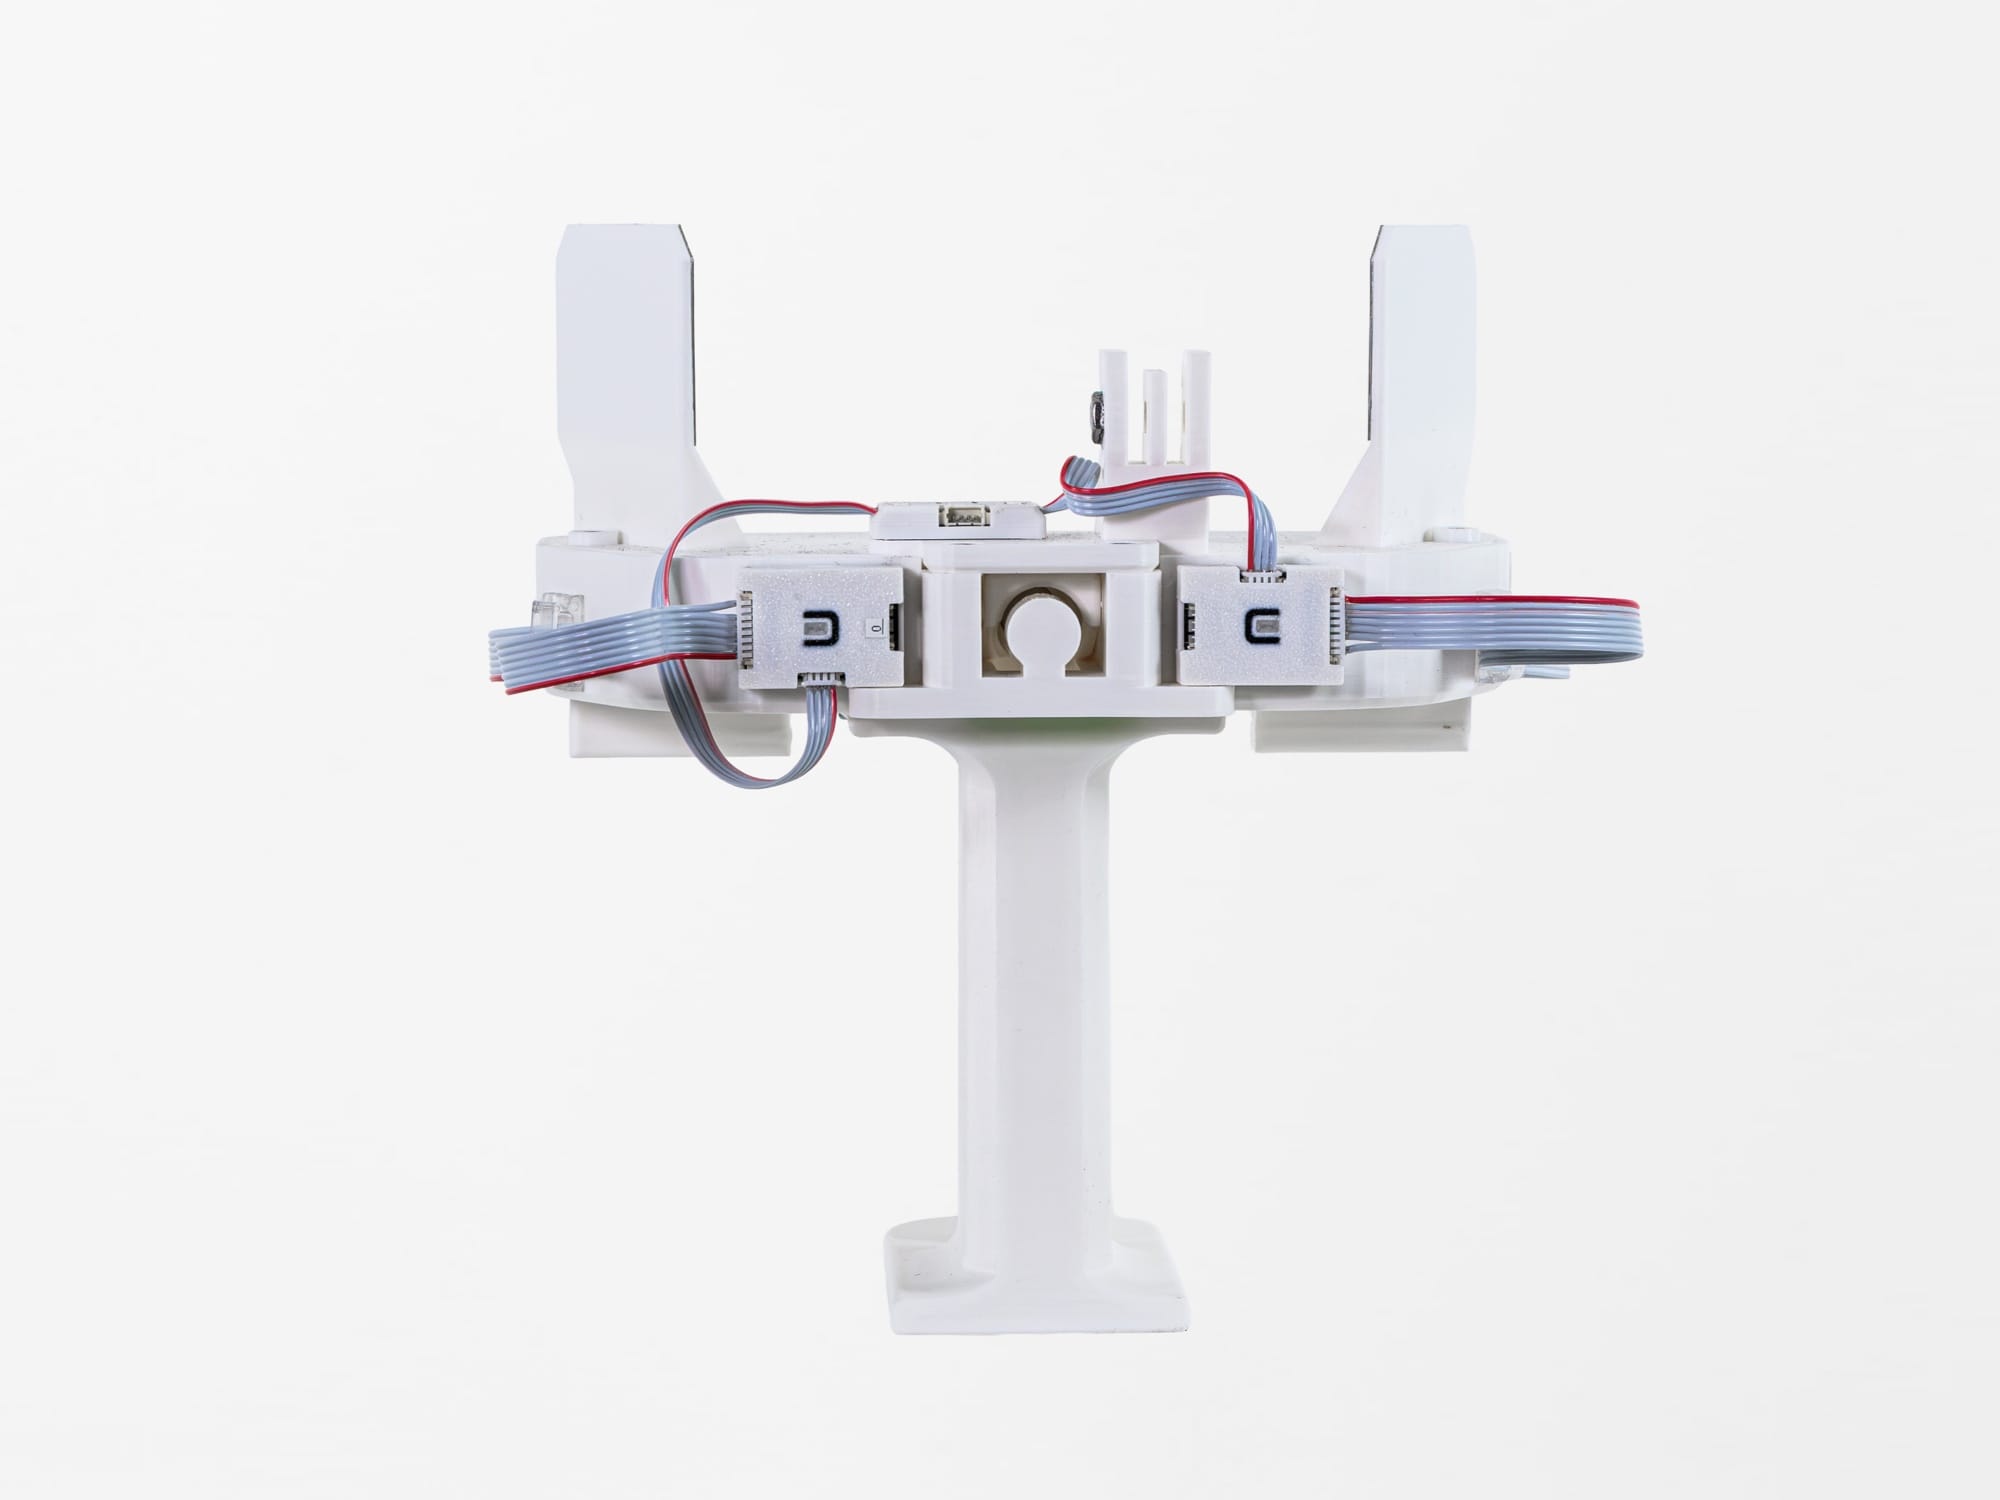

For UMI Gripper
Open Source Gripper
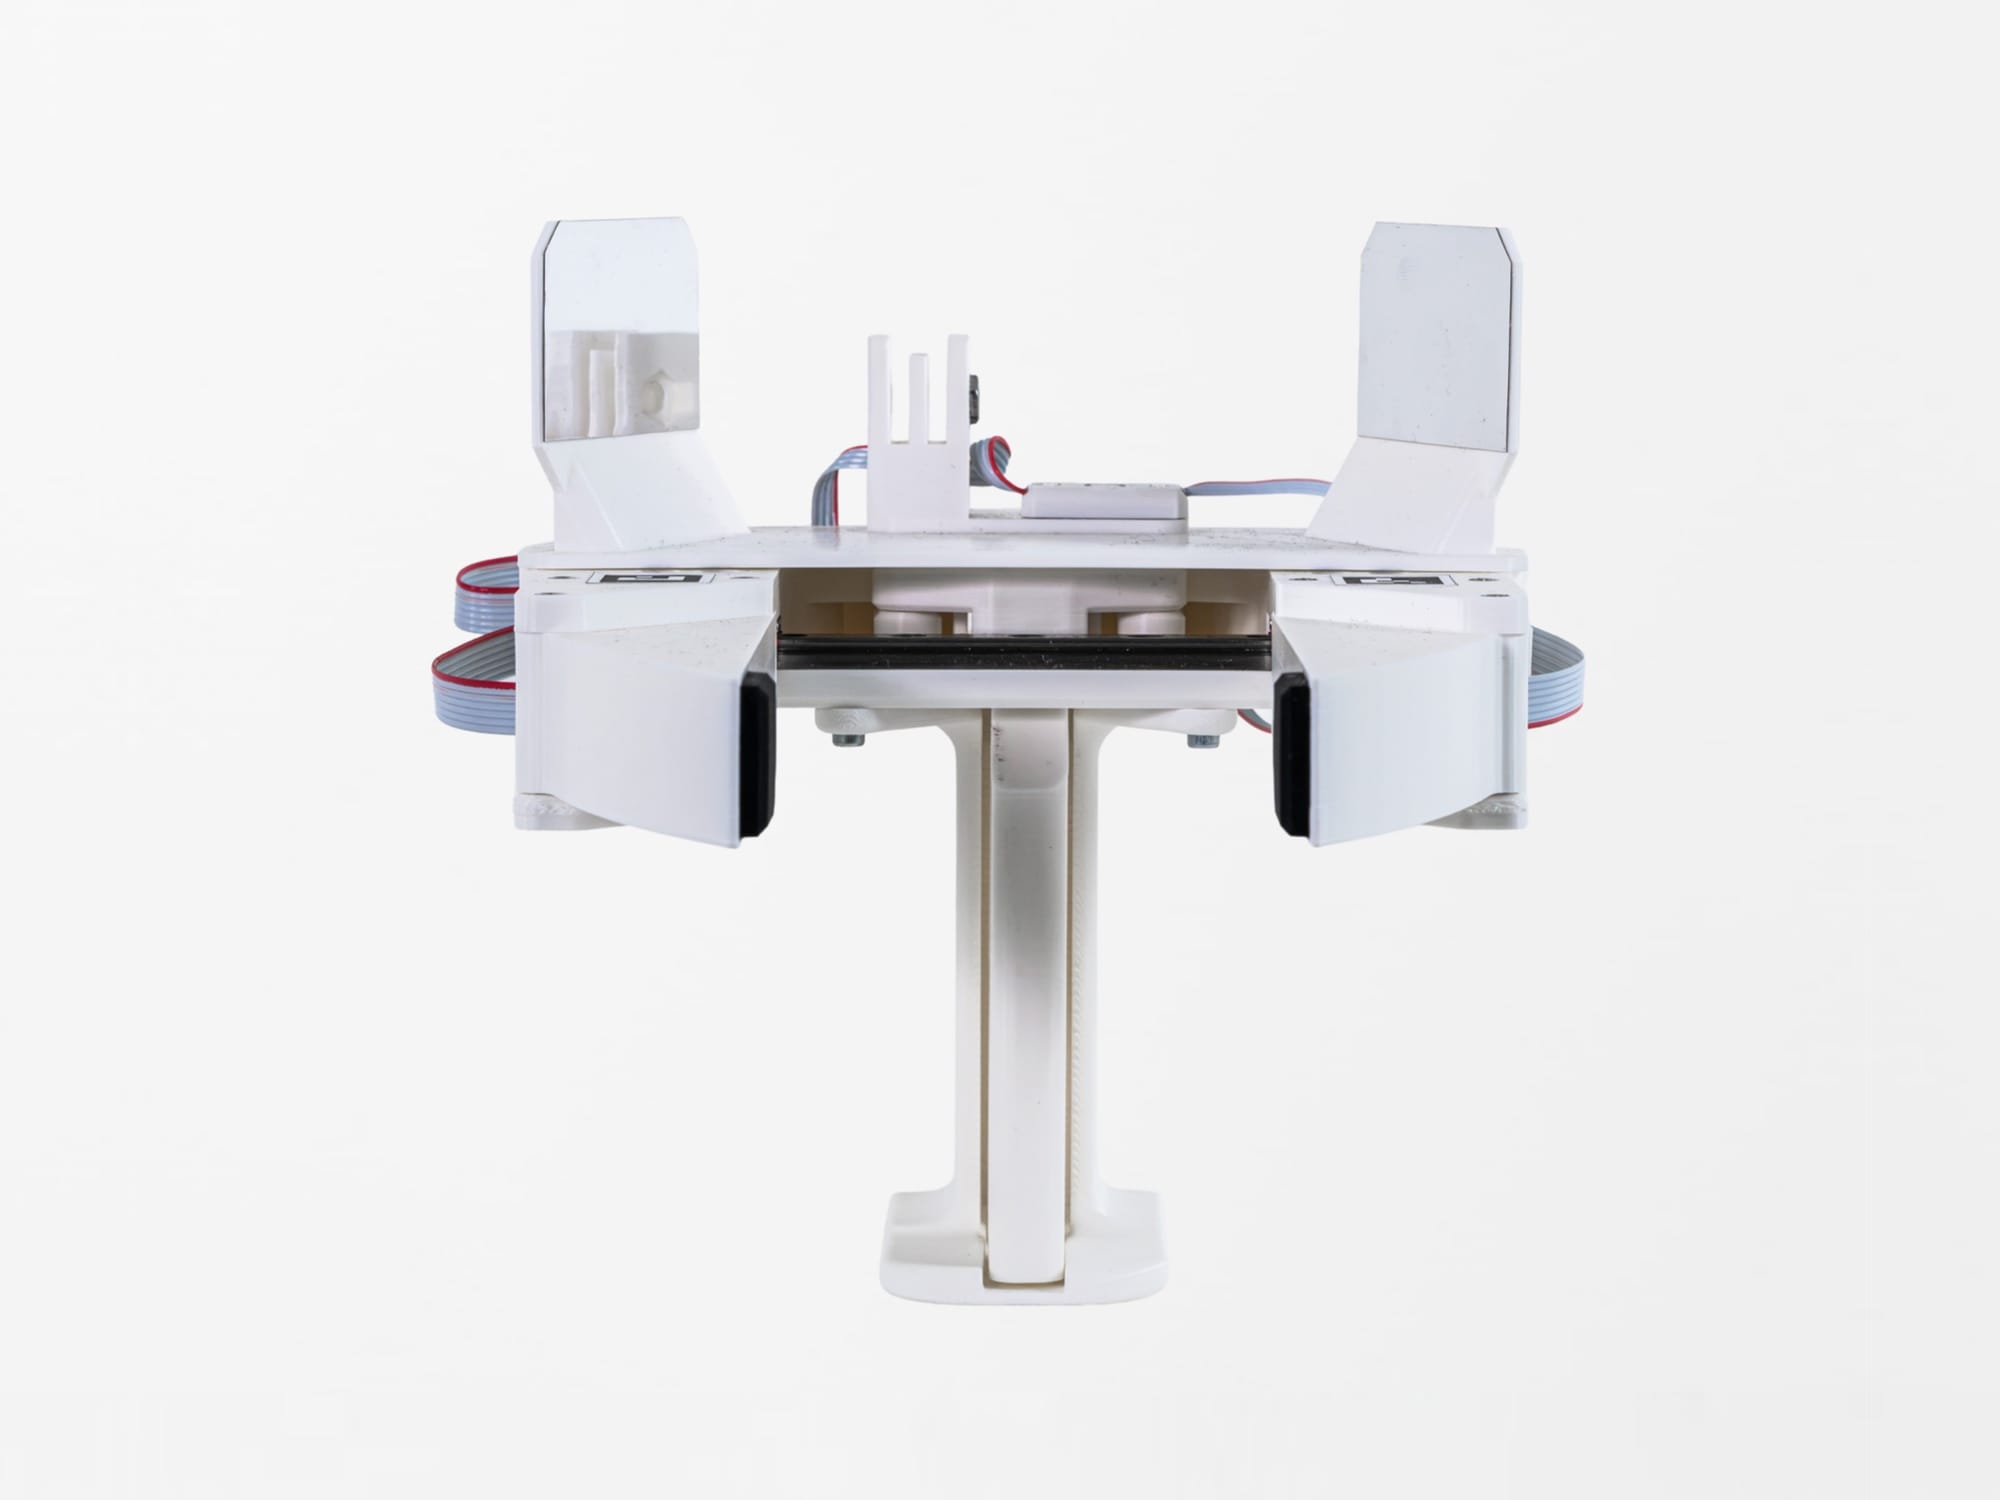
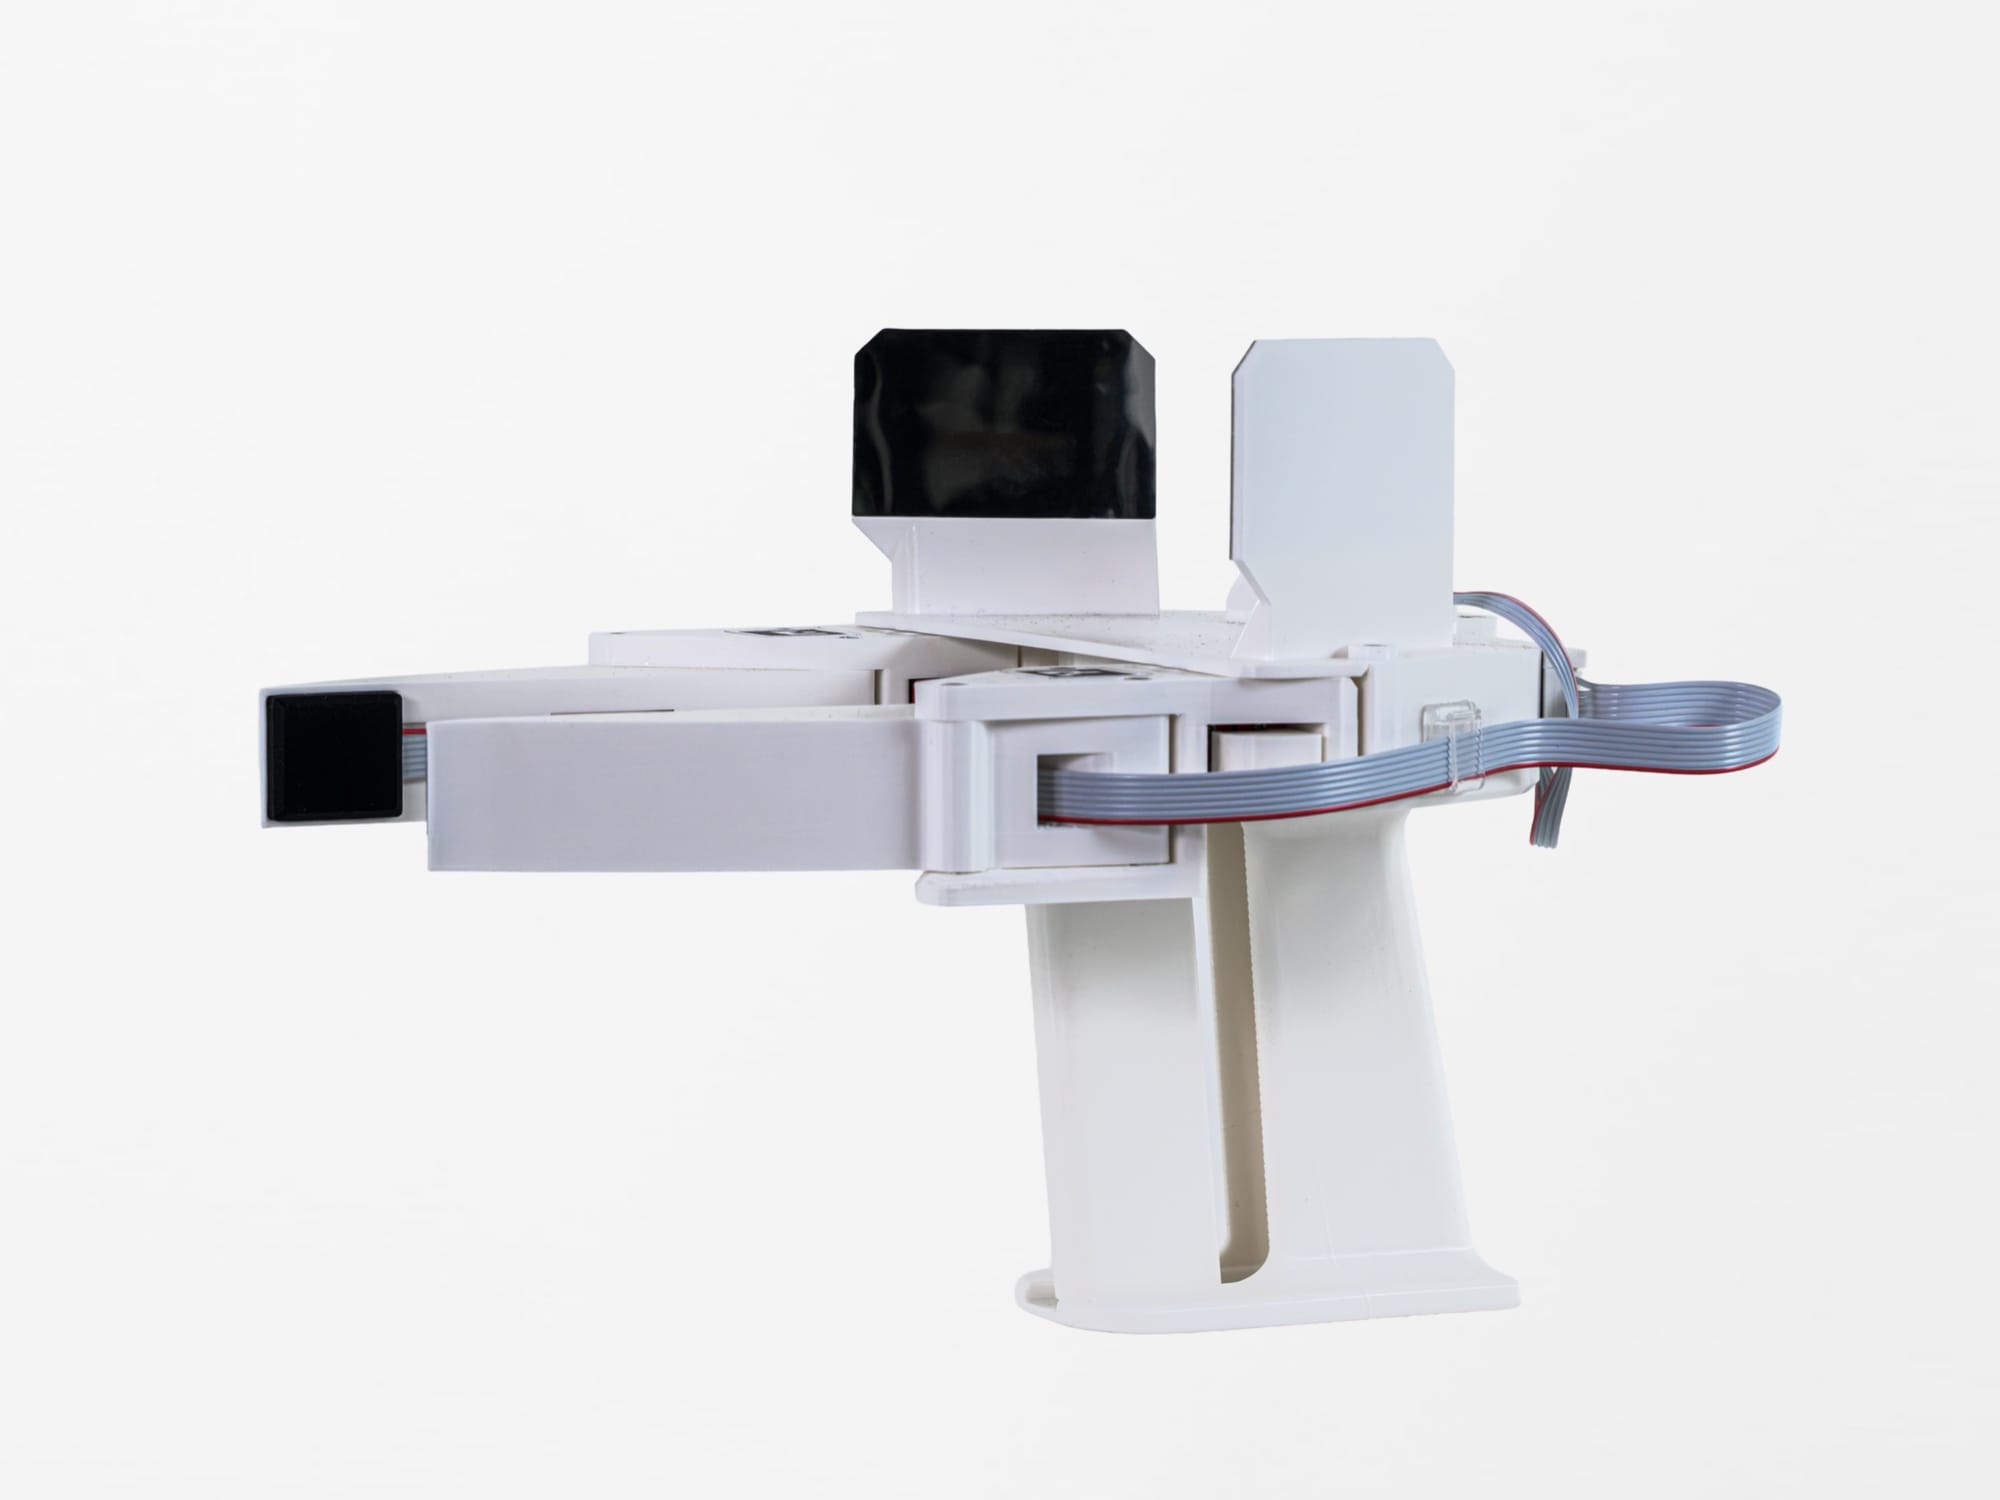
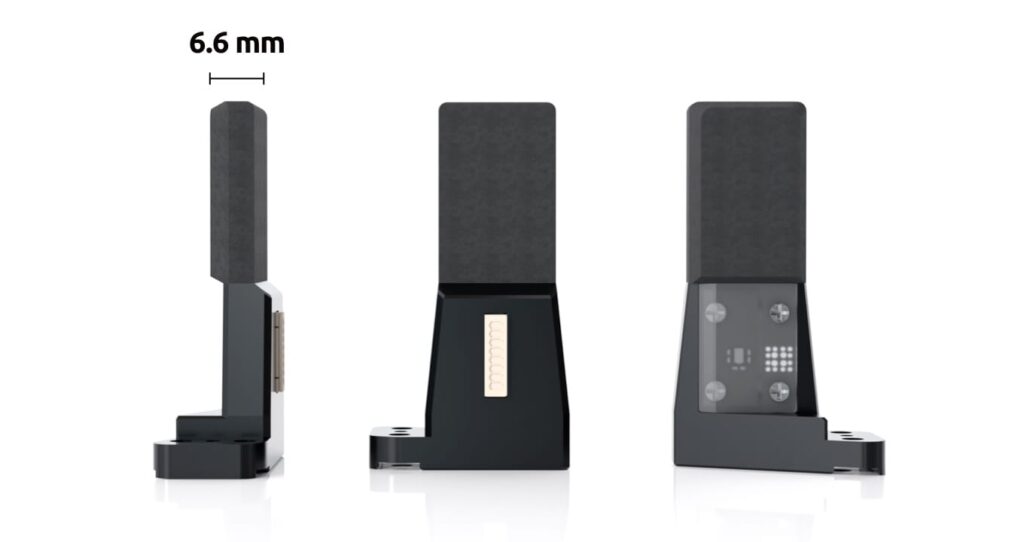
For the open source UMI (Universal Manipulation Interface) gripper, we have integrated our uSPa 44 in each fingertip. The microcontrollers are encapsulated, can be easily mounted to the back of the gripper with screws, and are included in the set.
Specifications
Type of sensor
uSkin Patch
Product code
Sensing points per module
16
Total sensing points
32
Measurements per sensing point
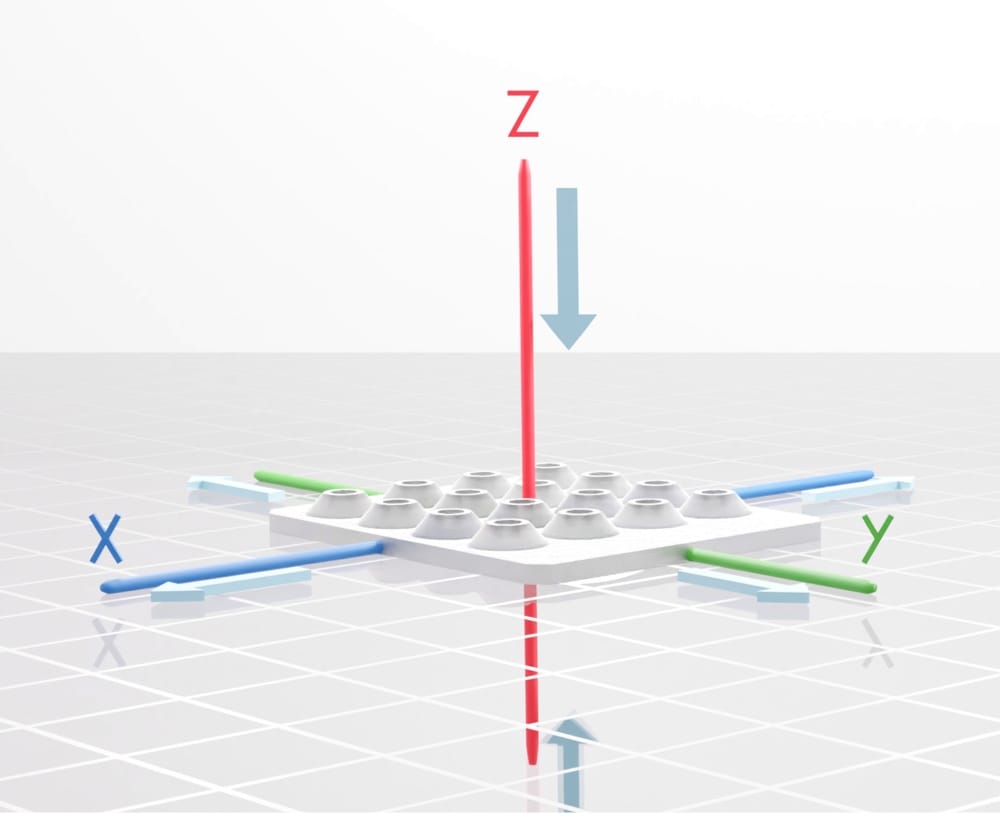
4 (3-axis touch and internal temperature)
Total number of measurements
32 sensing points × 4 = 128
Maximum sensing frequency
450 Hz
Sold individually: one fingertip per uSPa 44. To equip both fingers of the UMI gripper, you will need to order two uSPa 44.
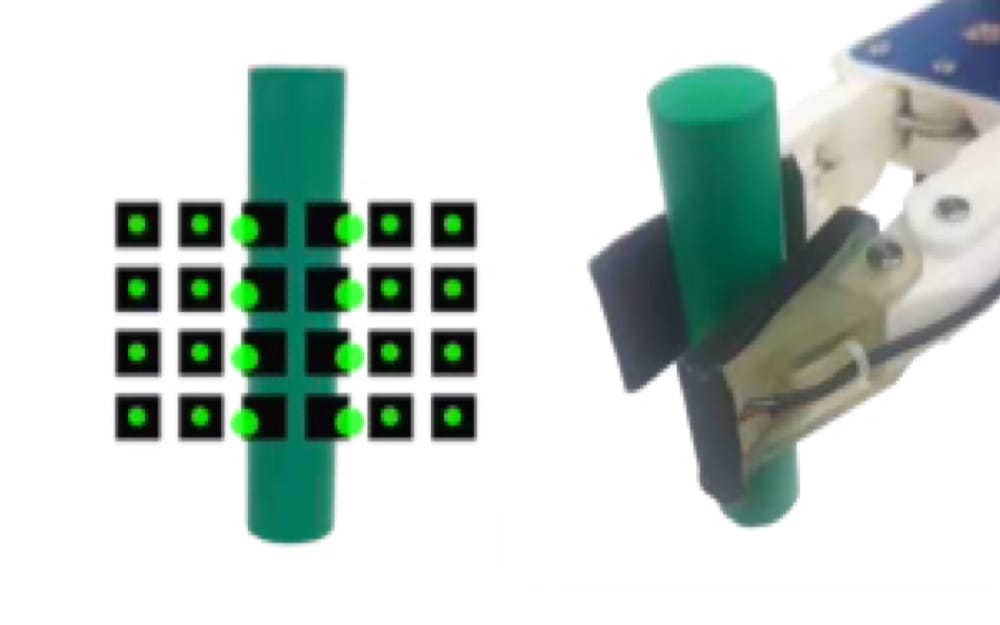
This integration enables AI for human-robot skill transfer by providing data collection from viewing humans doing everyday tasks, such as picking up a bottle of water and pouring it into a glass, and then transferring that skill to robot grippers. uSkin provides the ability to add distributed force-vector measurements to the data collection.
Sensors connect directly to uAi Software for visualization, calibration, and compensation, providing consistent tactile data across diverse applications.
Compact Sensing Points

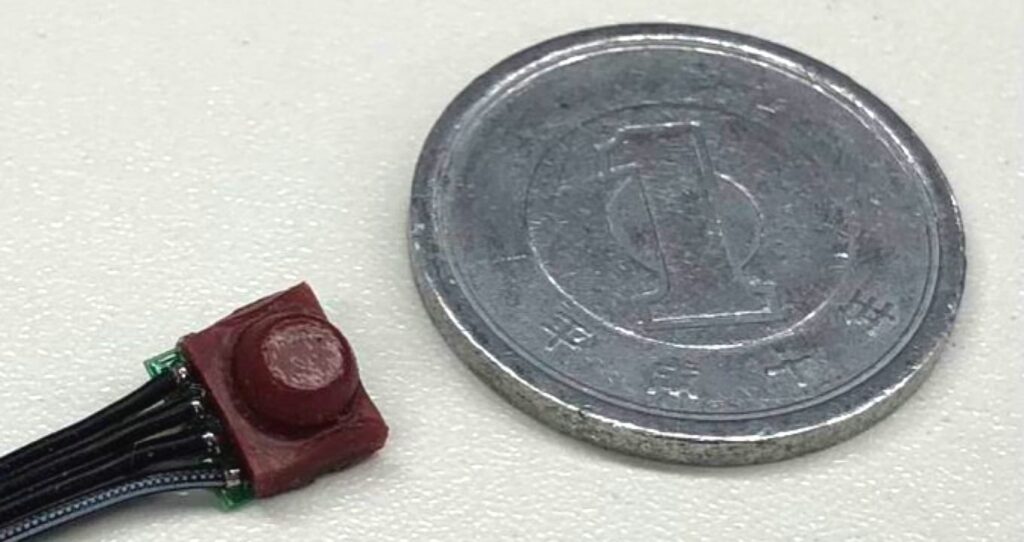
Distributed 3-axis Sensing
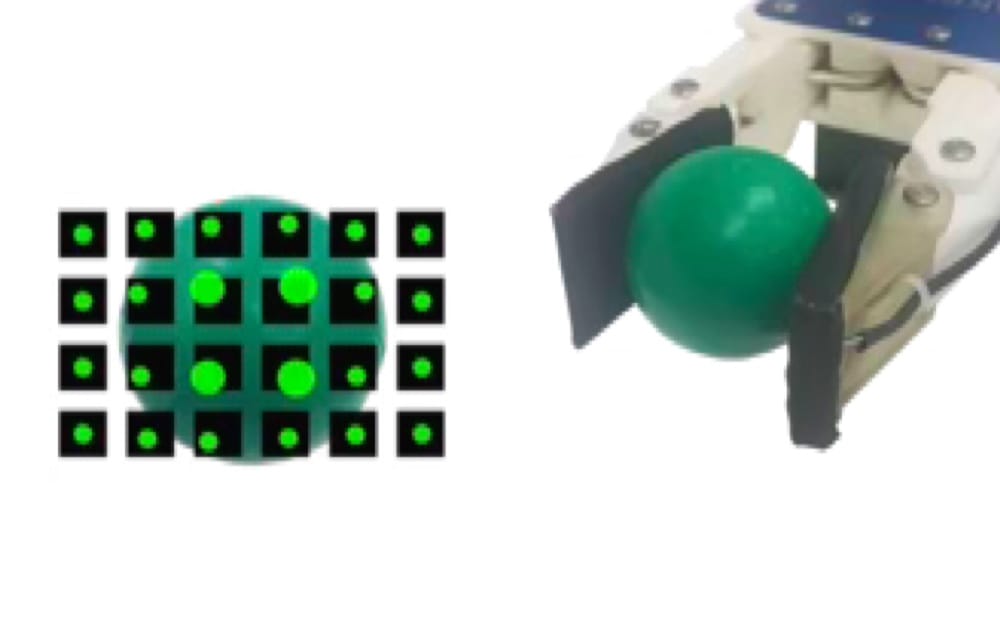
Sensitive: 0.1 gram-force Resolution
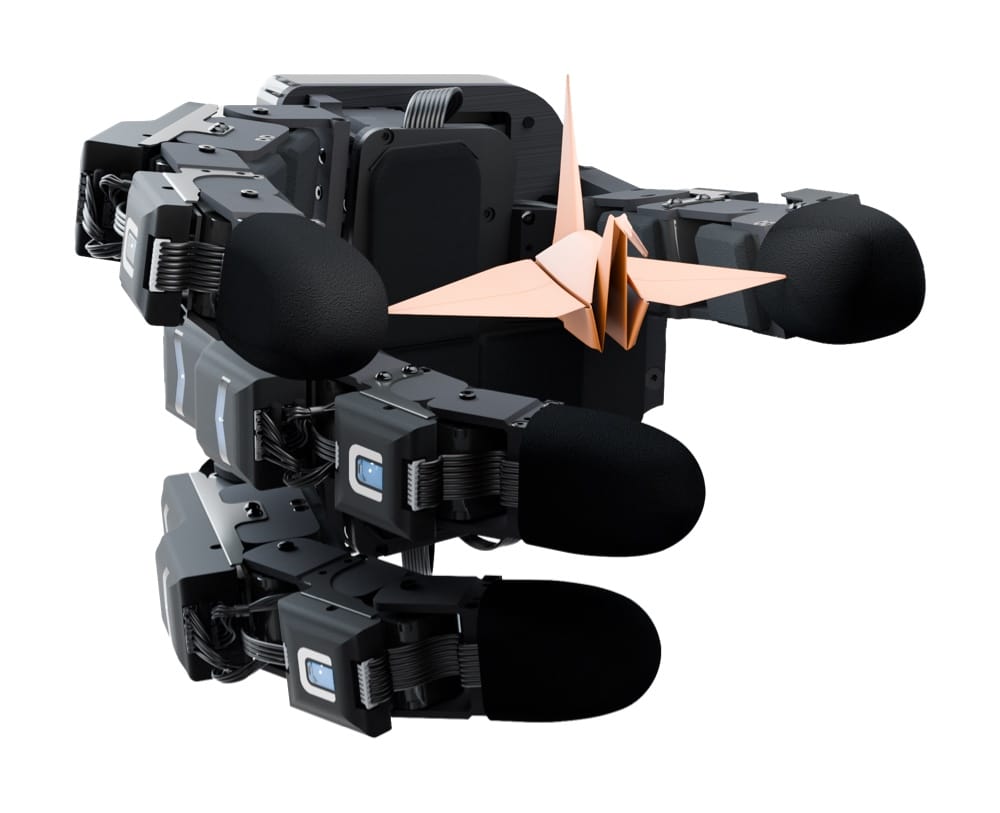
Soft & Robust
Minimal Wiring & Fast Sampling: 500 Hz
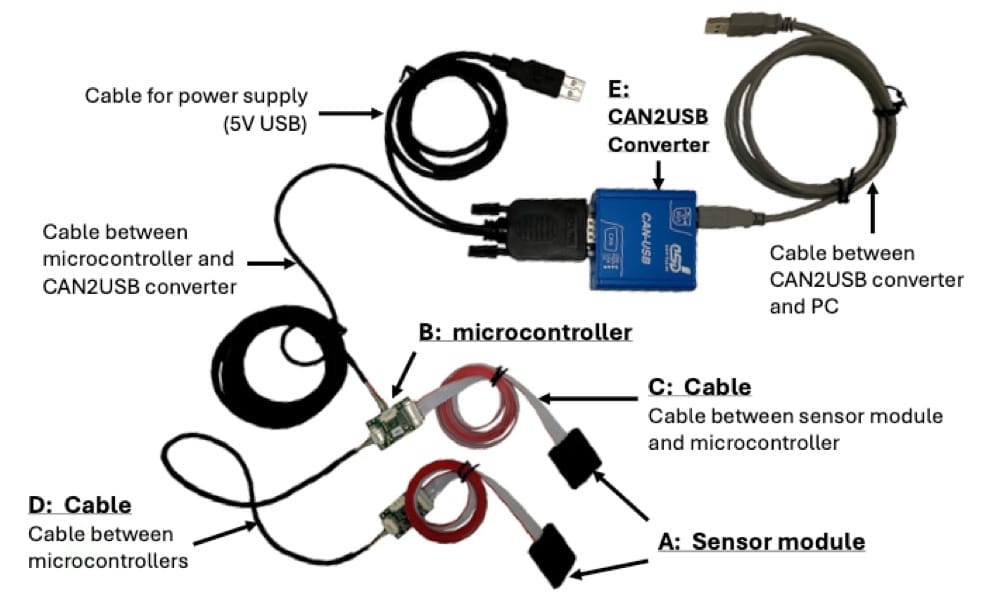
Easy to Integrate & Use
Calibrated in Newtons
Temperature & Magnetic Compensation
Process, visualize, and analyze tactile data with uAi software
XELA’s software platform for processing tactile data from uSkin sensors.