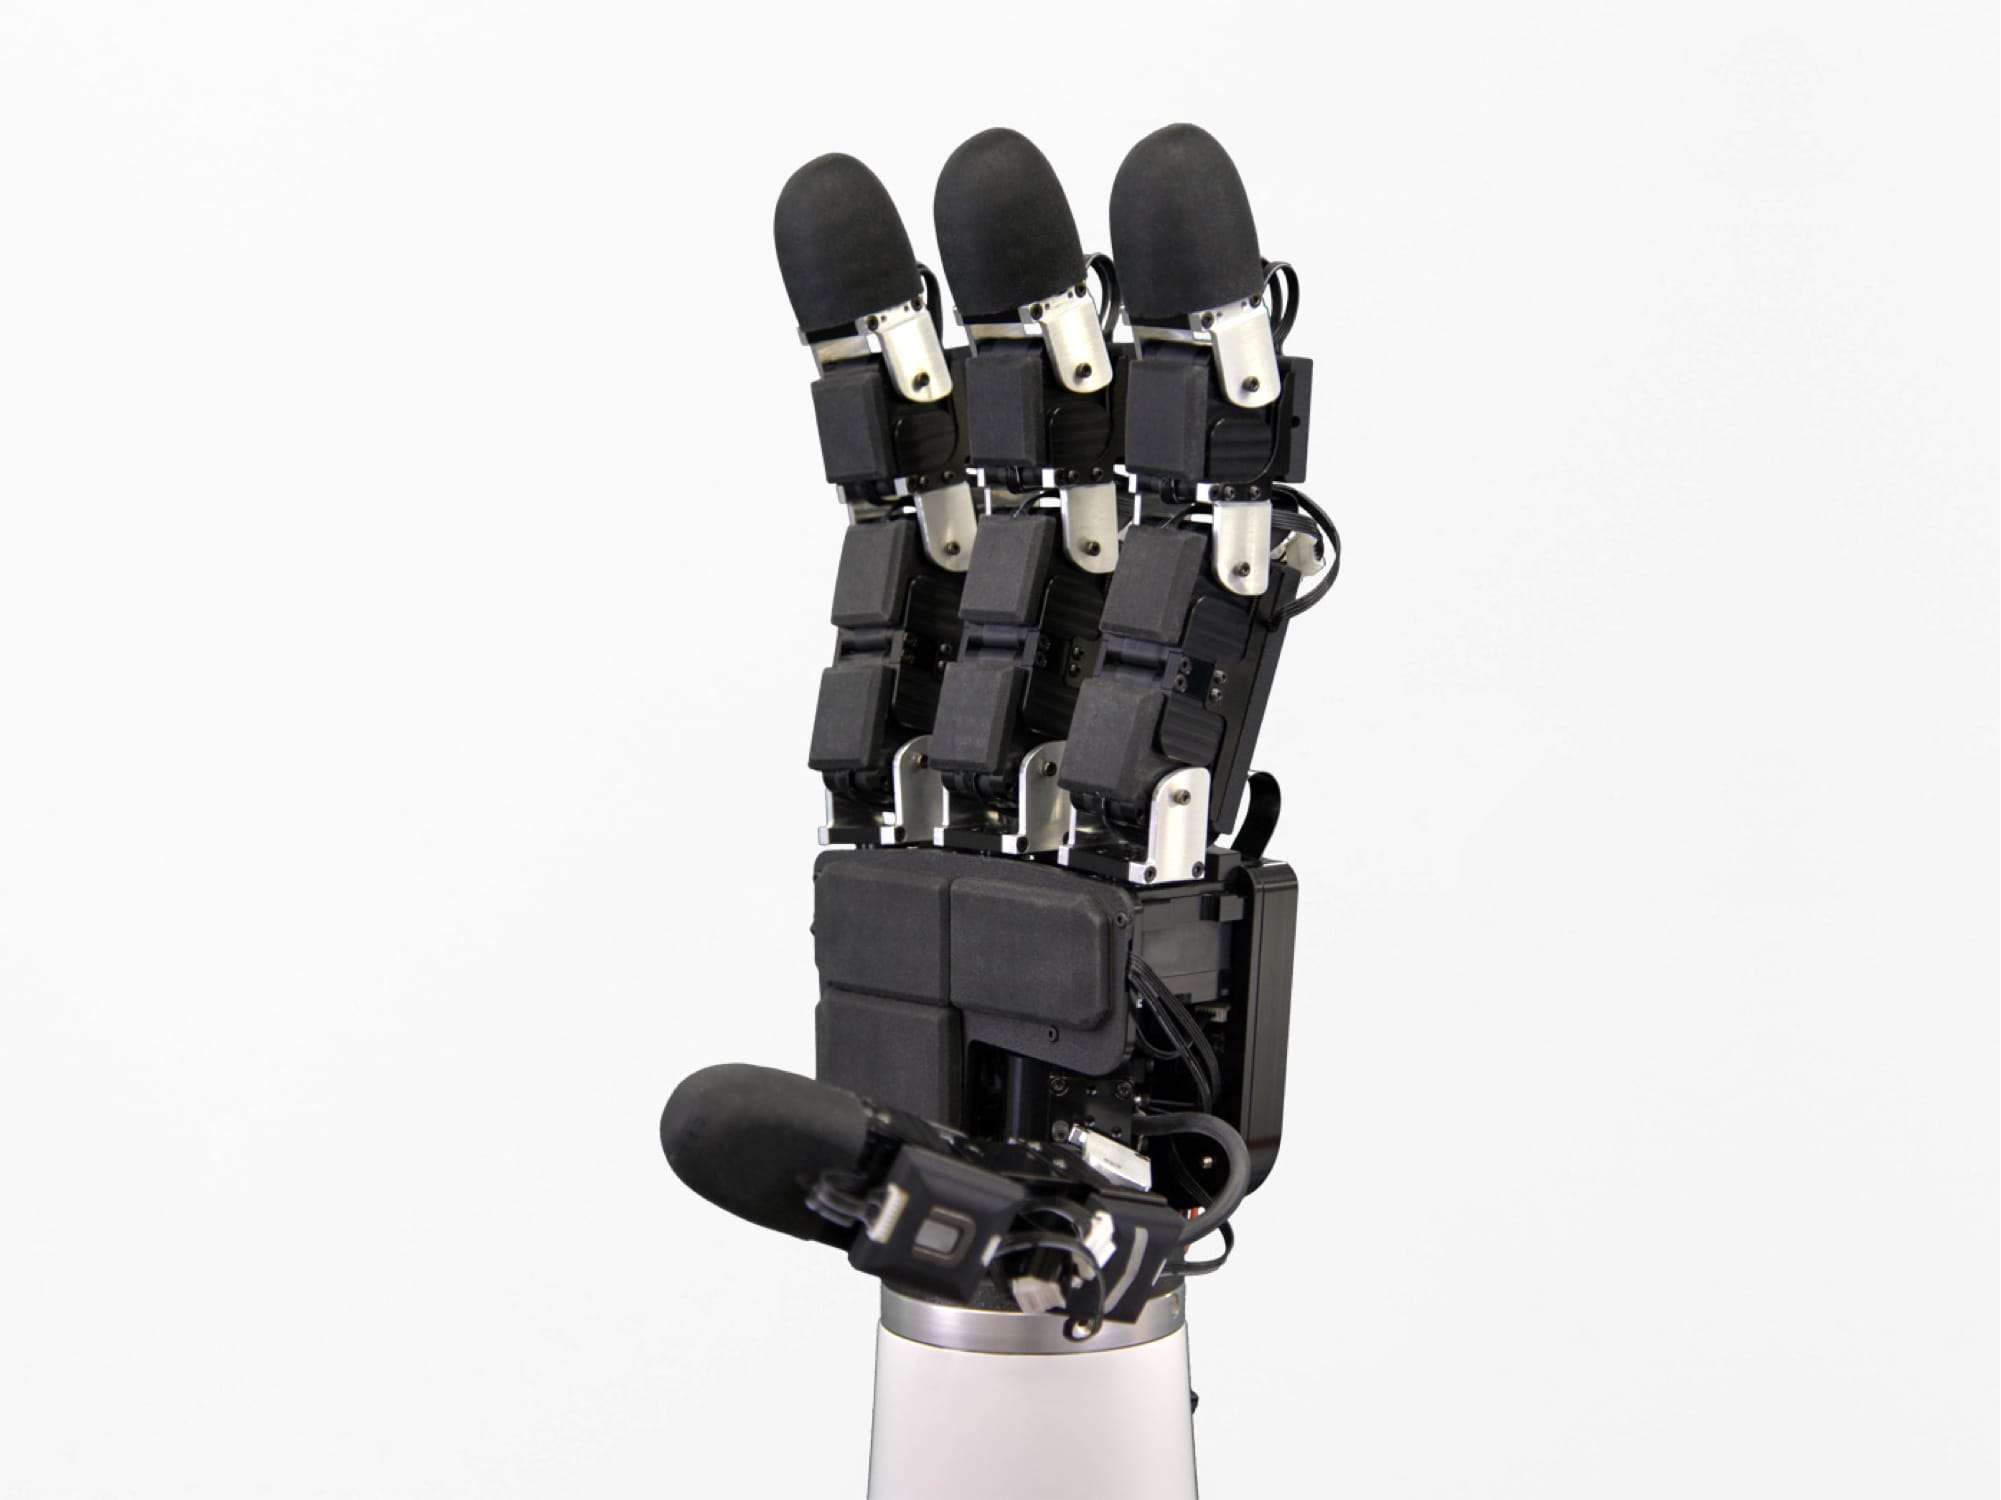
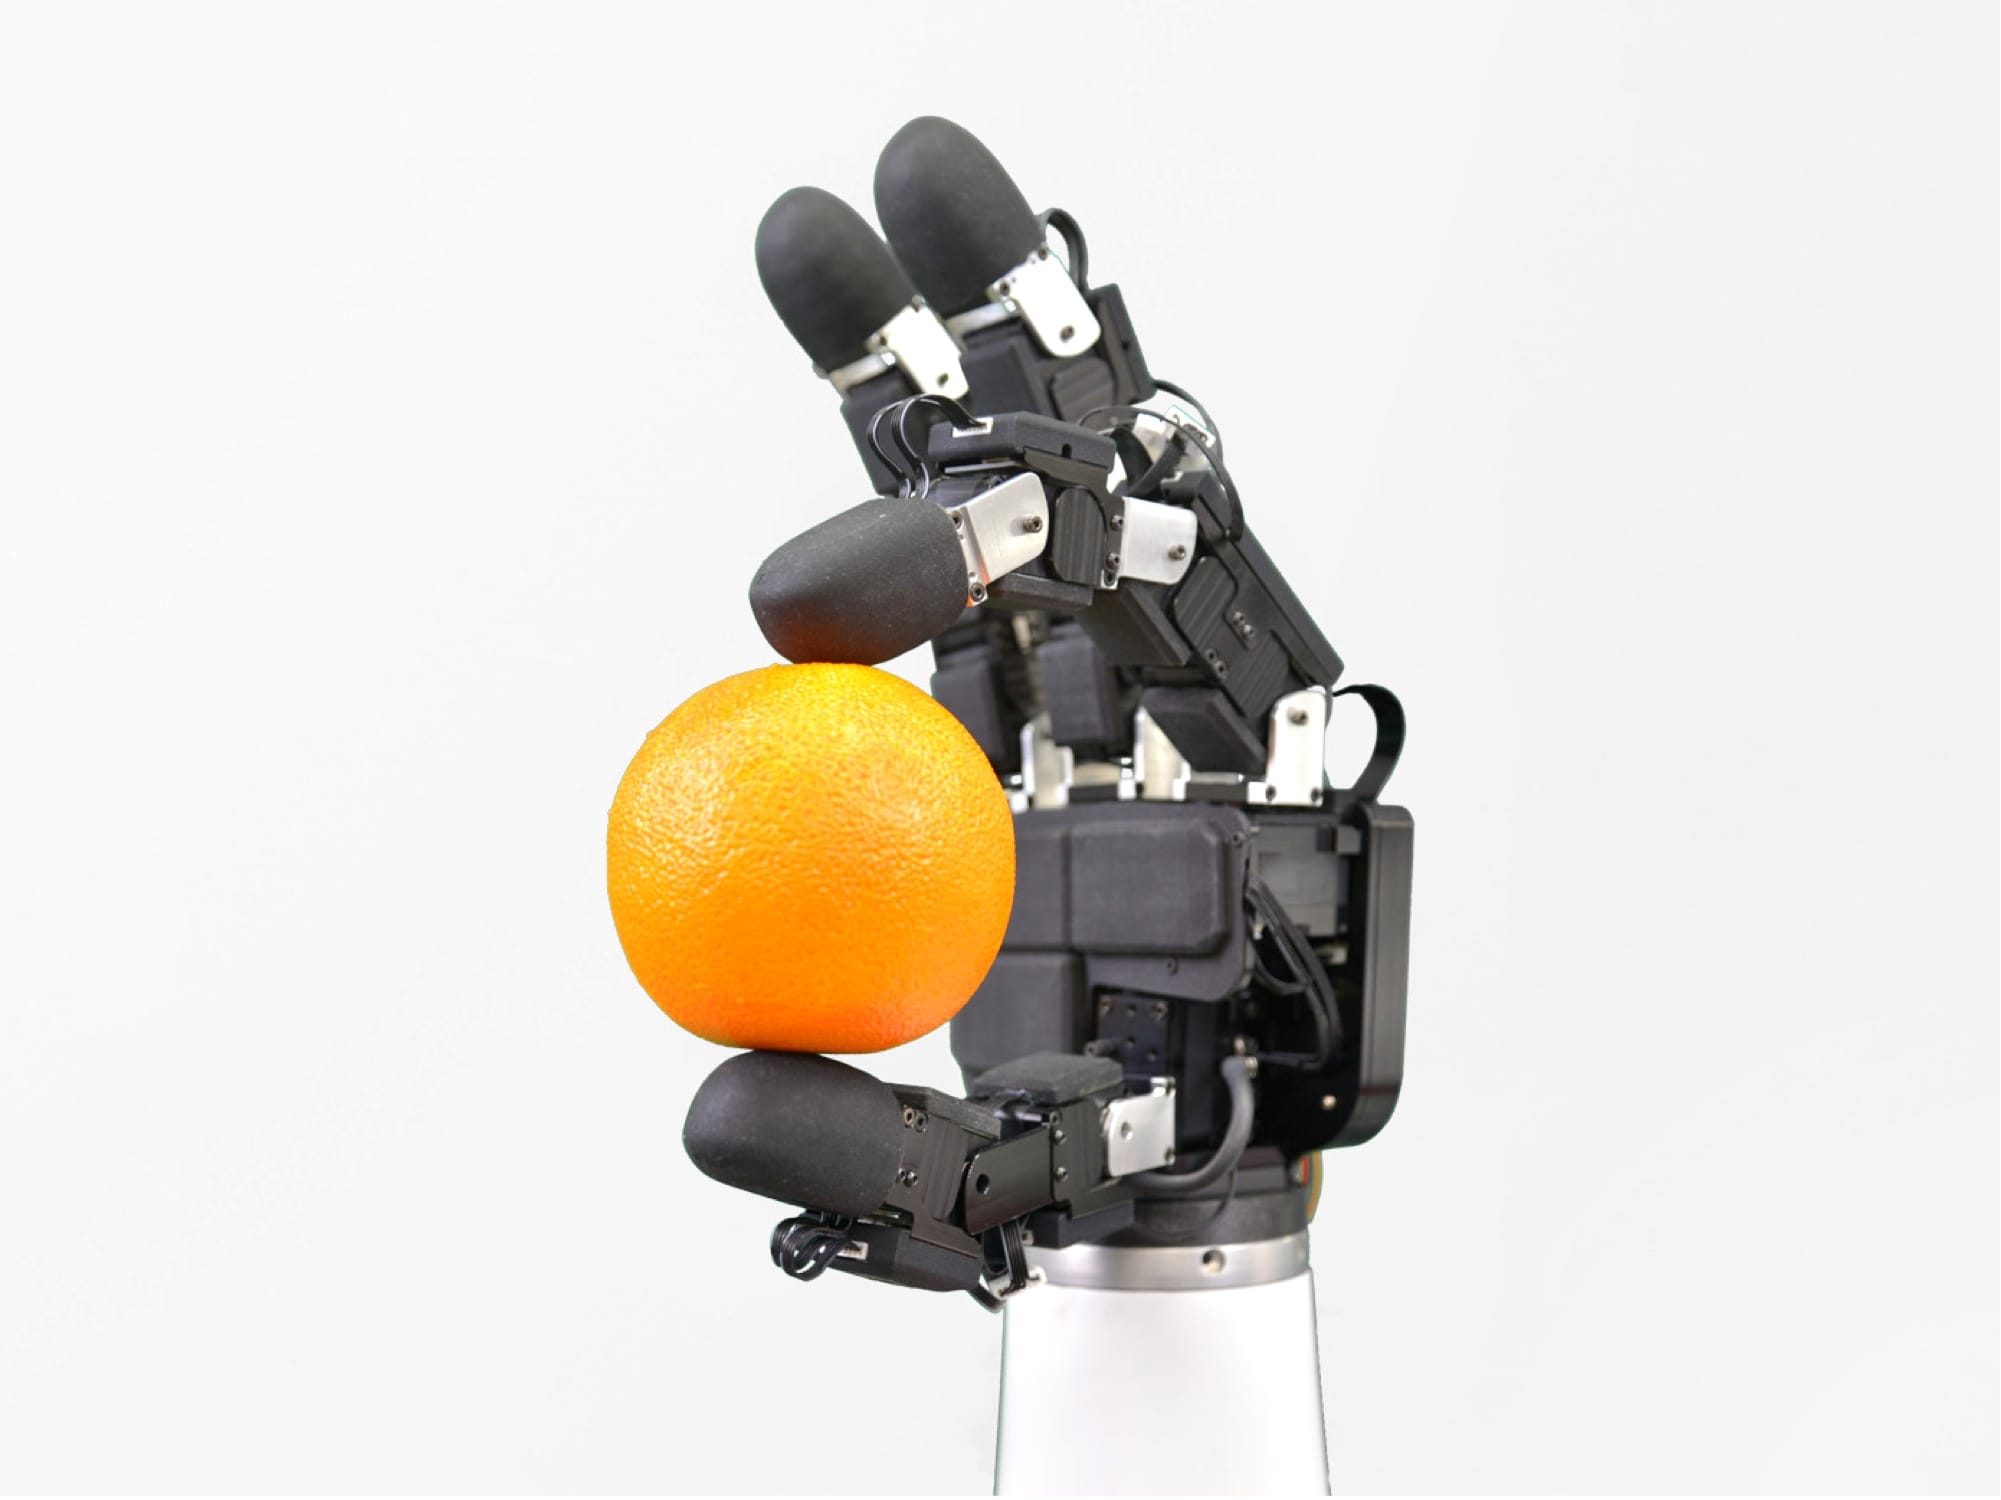

For Allegro Hand V4 Curved
by WONIK Robotics
1,472 measurements with minimal wiring.
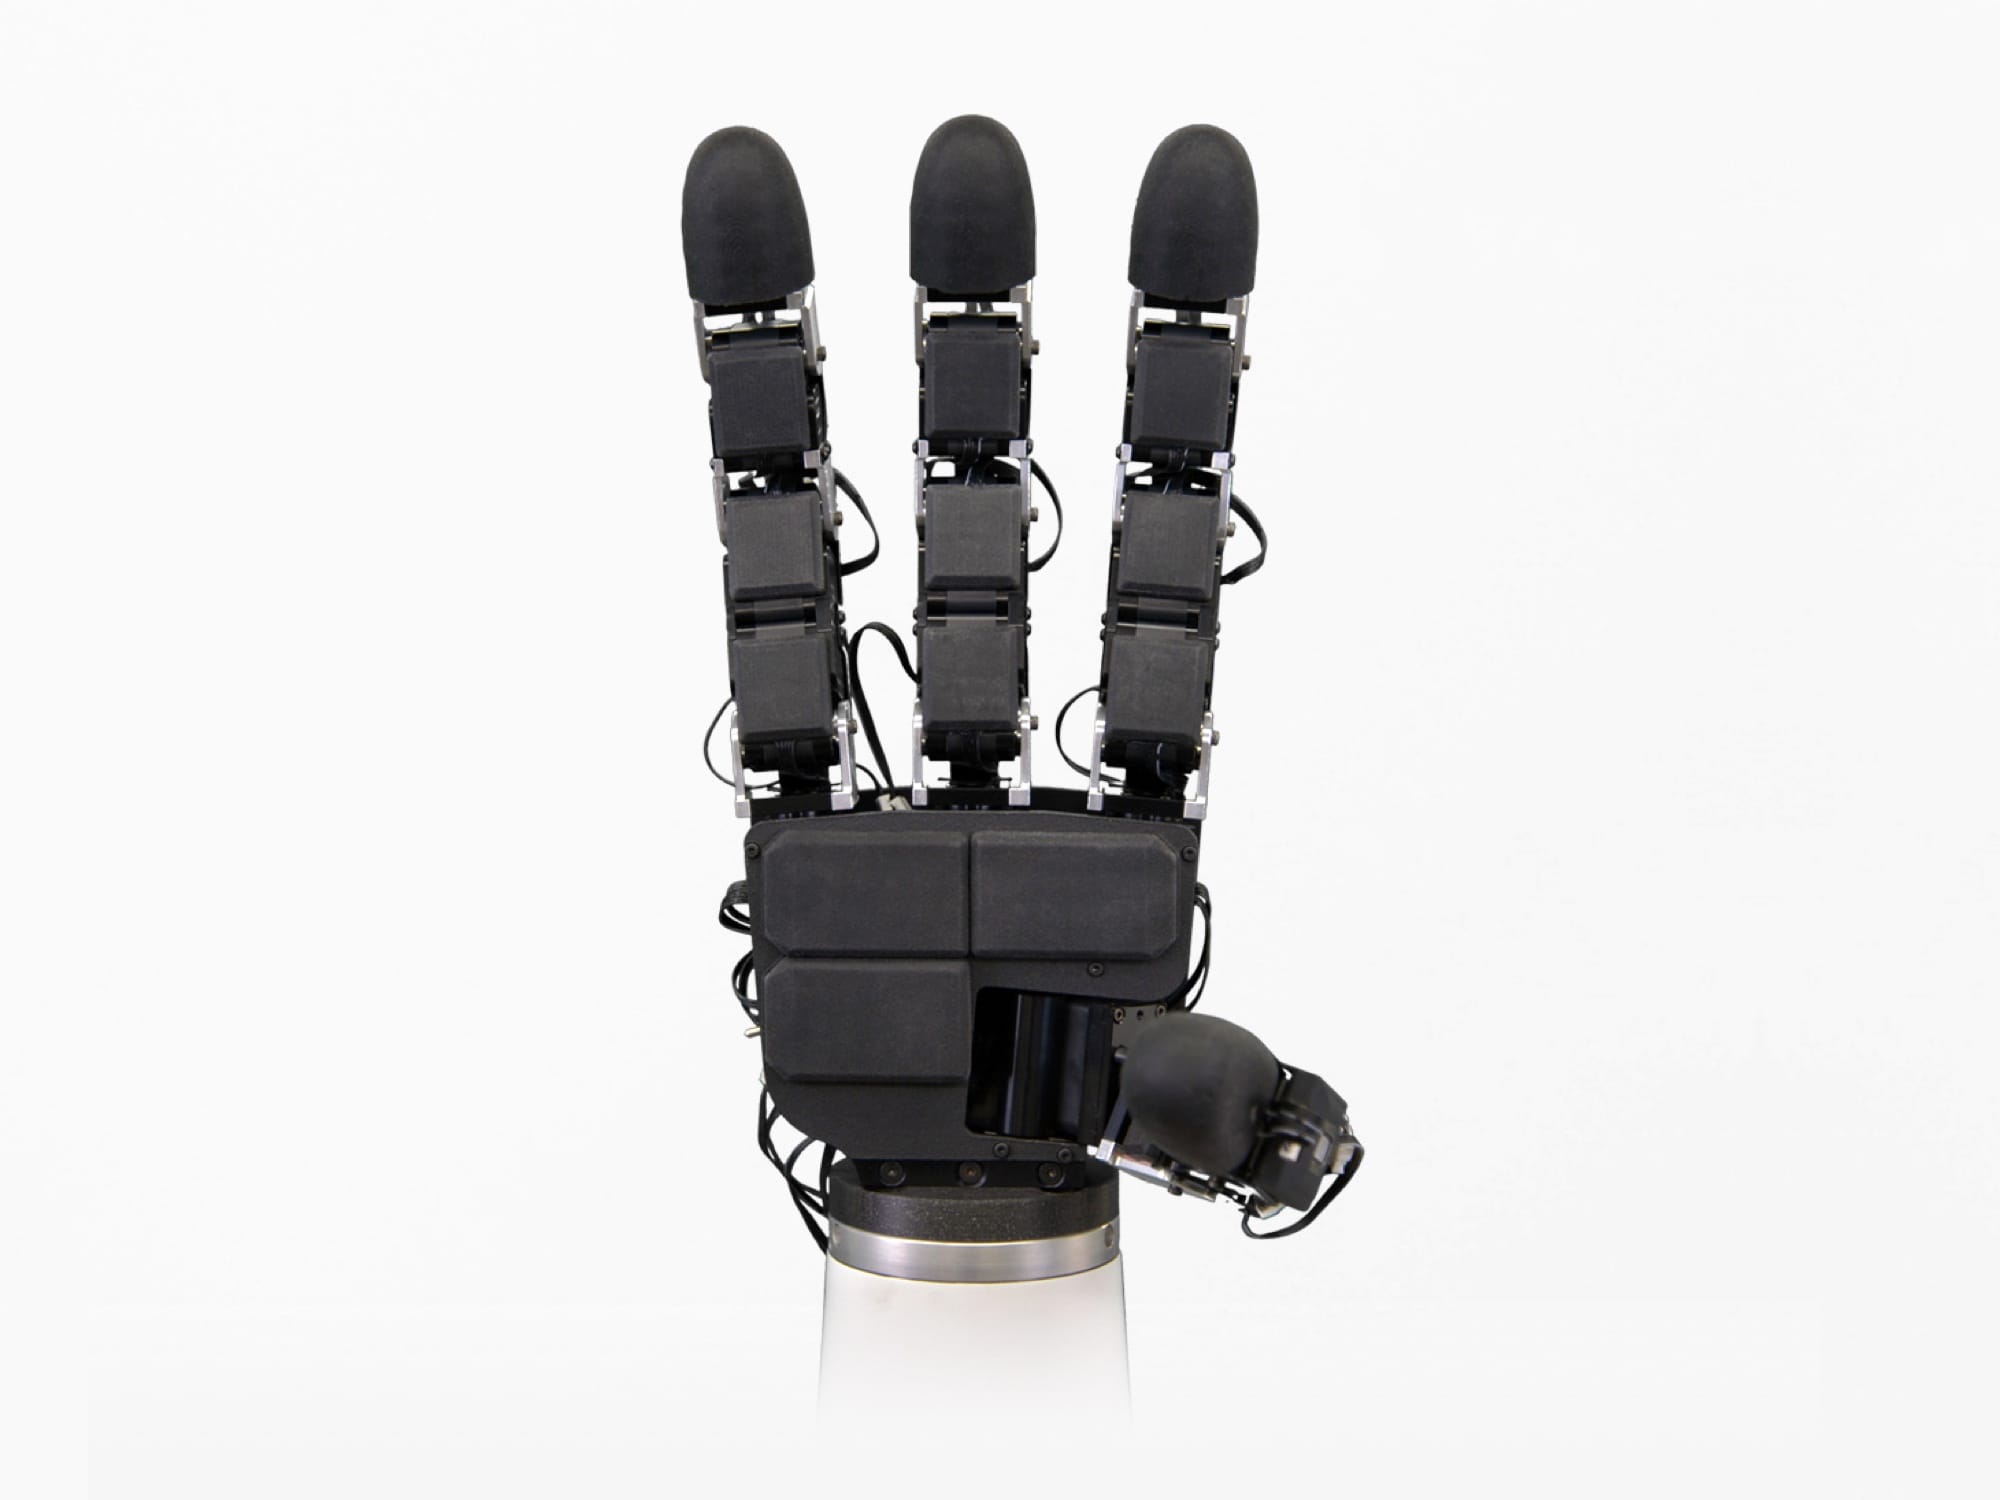
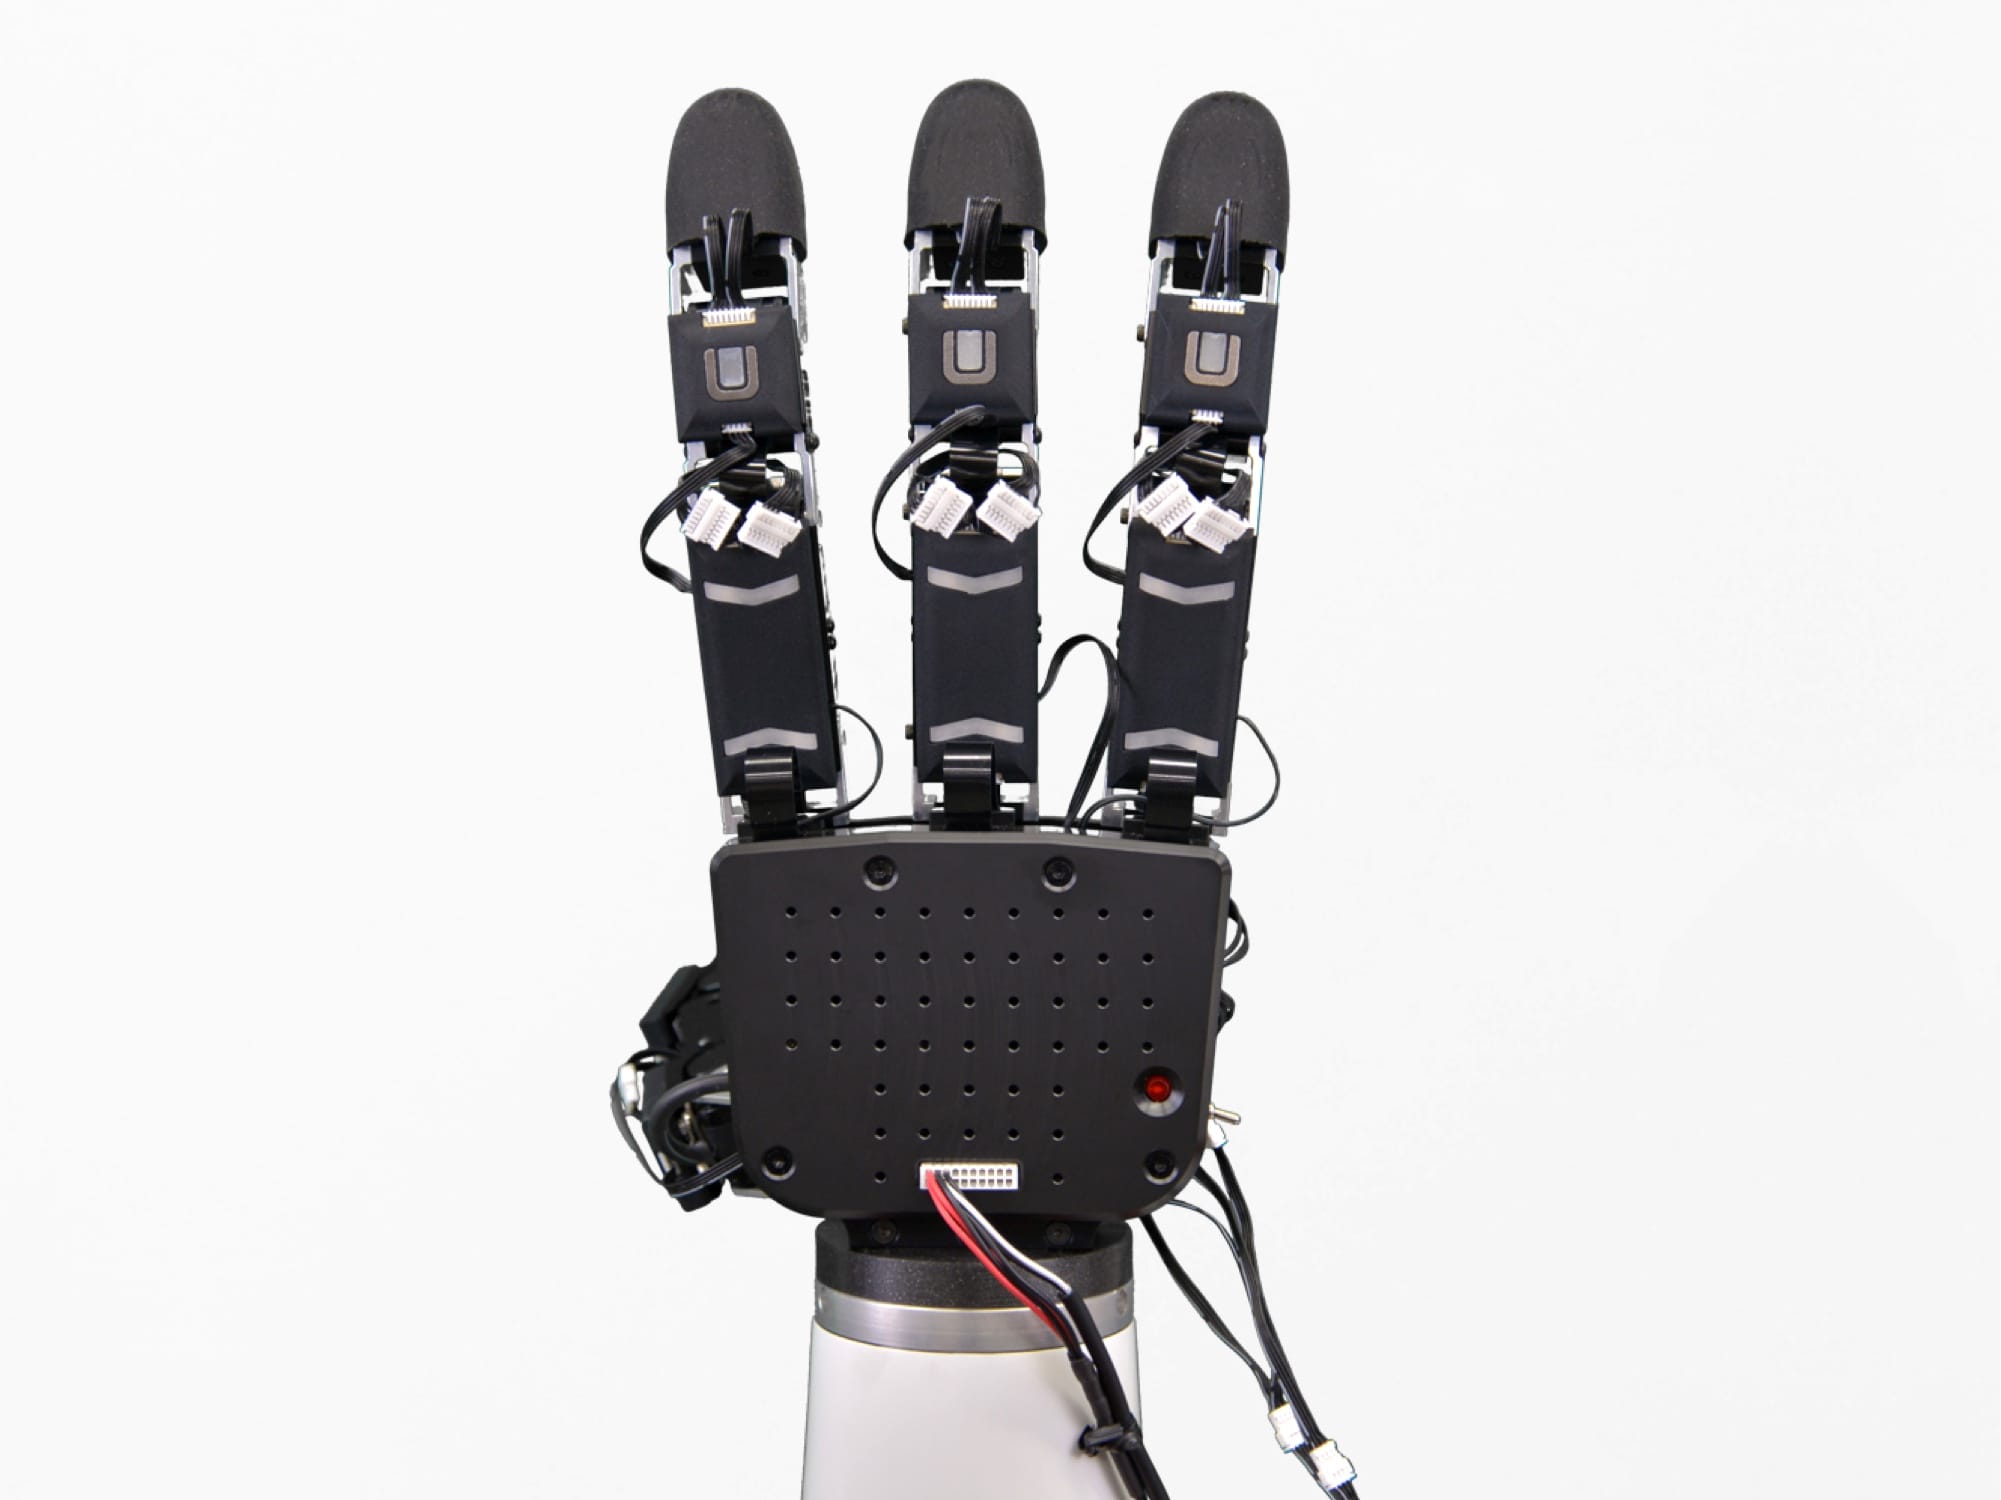
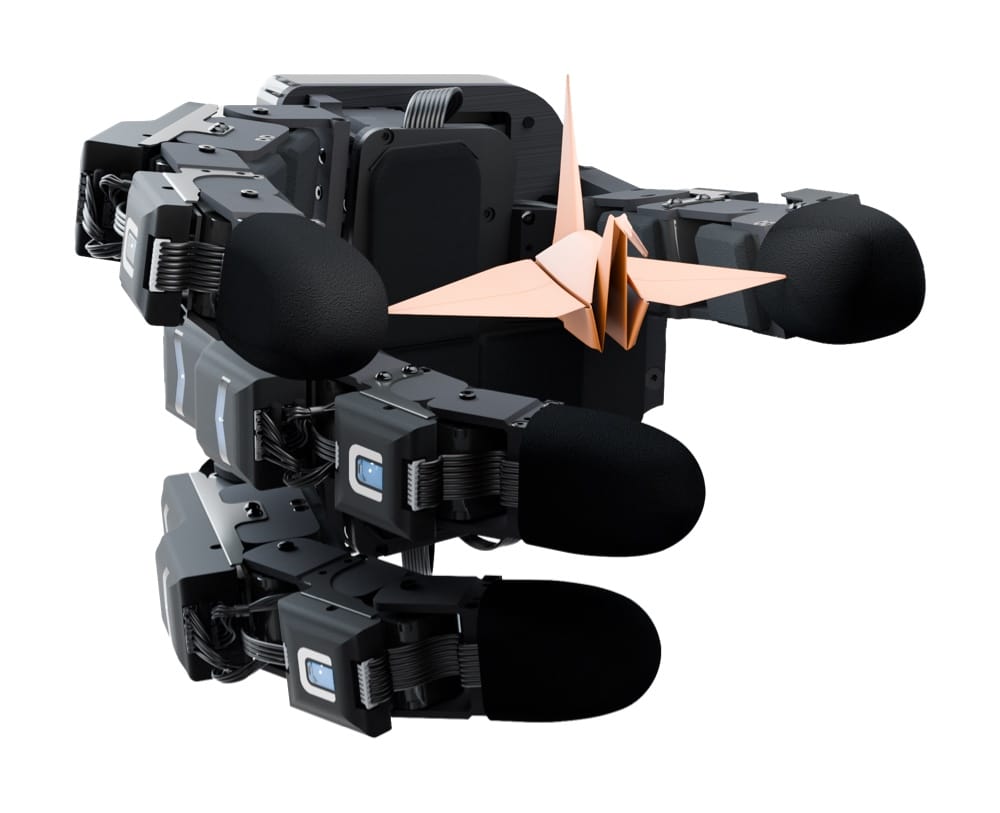
Designed for the Allegro Hand V4 by Wonik Robotics, this fully sensorized hand combines curved uSkin sensors on the fingertips with flat sensors on the phalanges and palm. The curved fingertip design enables more natural object interaction, and its outer layer can be replaced for long-term reliability. The microcontrollers are encapsulated and are mounted to the back of the fingers and the inside of the palm. The integration comes with all required parts; the installation of the fingertips is straightforward (the phalanges and palm require additional steps). Users can choose which part of the hand to cover with sensors. Only one cable with four wires is required for each finger, and two cables for the whole hand (two CAN bus cables).
Specifications
Type of sensor
uSkin ALHA (fingertips) + uSkin Patch (phalanges and palm)
Sensing points per fingertip
30
Sensing points per phalange
16
Sensing points palm
72
Total sensing points
4 fingertips × 30 + 11 phalanges × 16 + 72 (palm) = 368
Measurements per sensing point
4 (3-axis touch and internal temperature)
Total number of measurements
368 × 4 = 1,472
Maximum sensing frequency
275 Hz (up to 450 for the phalanges and palm depending on the configuration)
Sensors connect directly to uAi Software for visualization, calibration, and compensation, providing consistent tactile data across diverse applications.
Compact Sensing Points

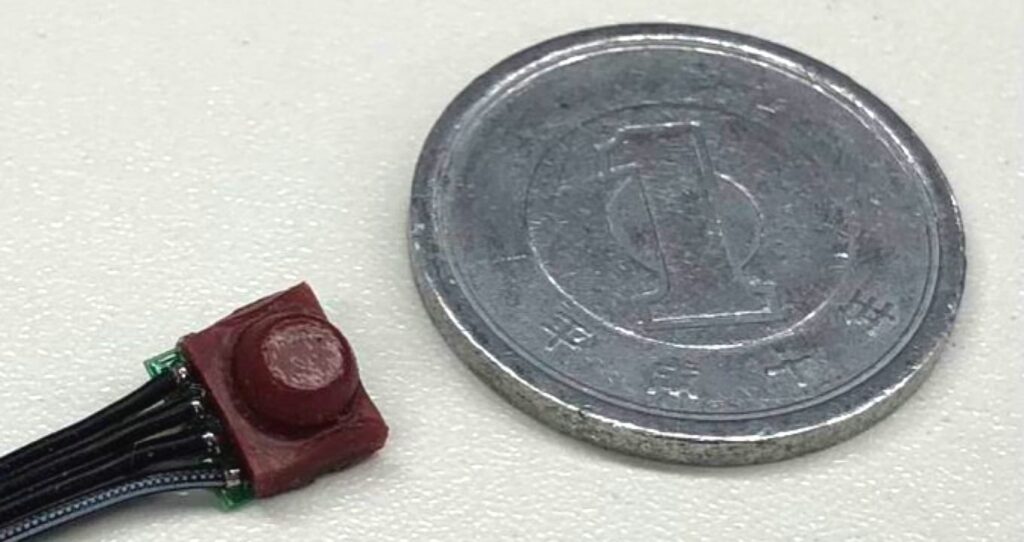
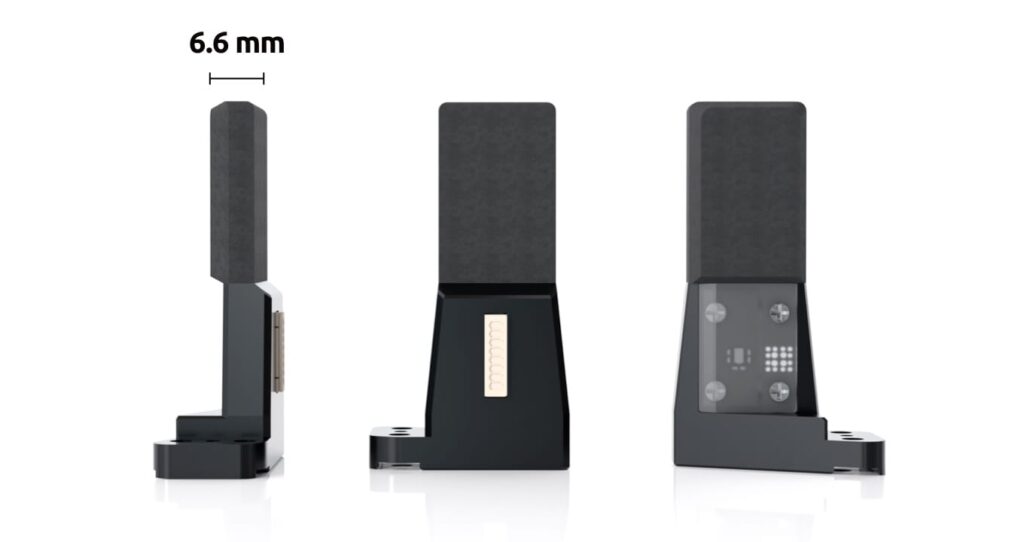
Distributed 3-axis Sensing
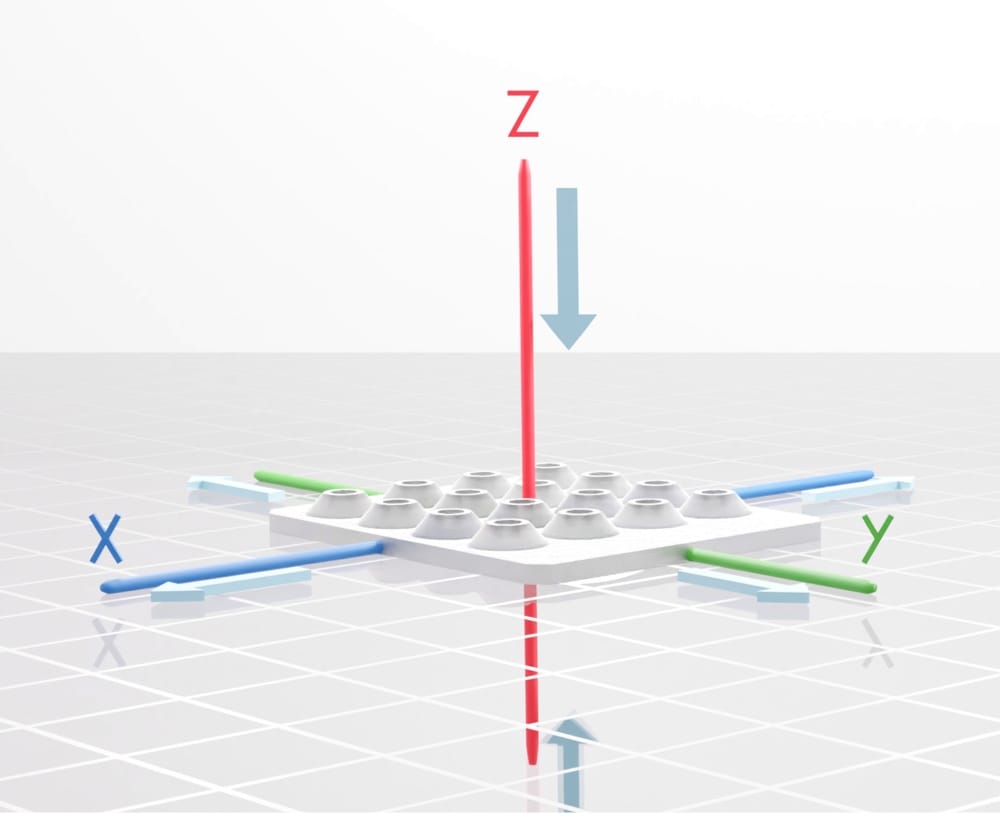
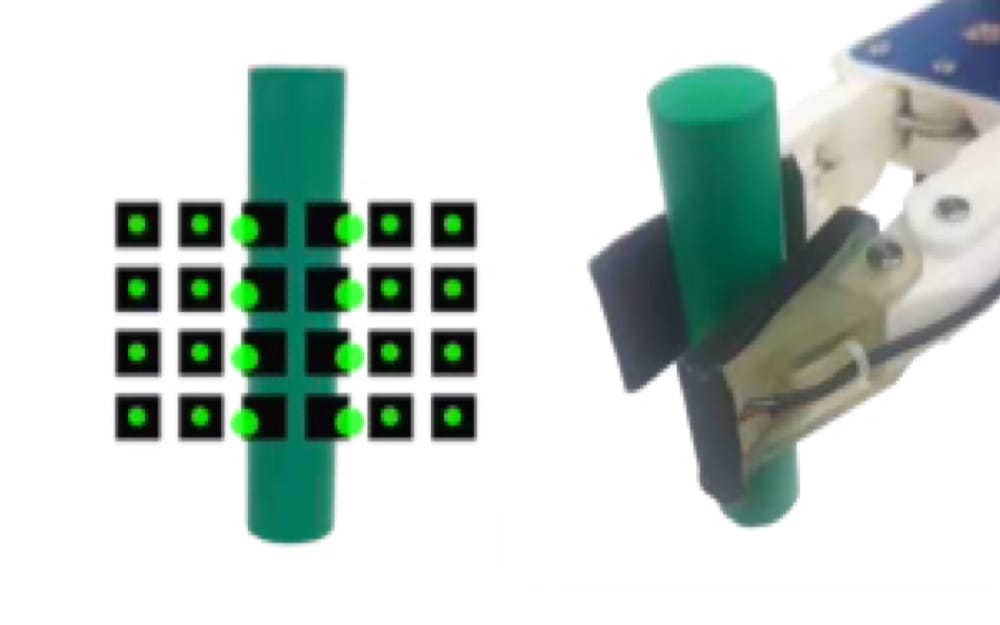
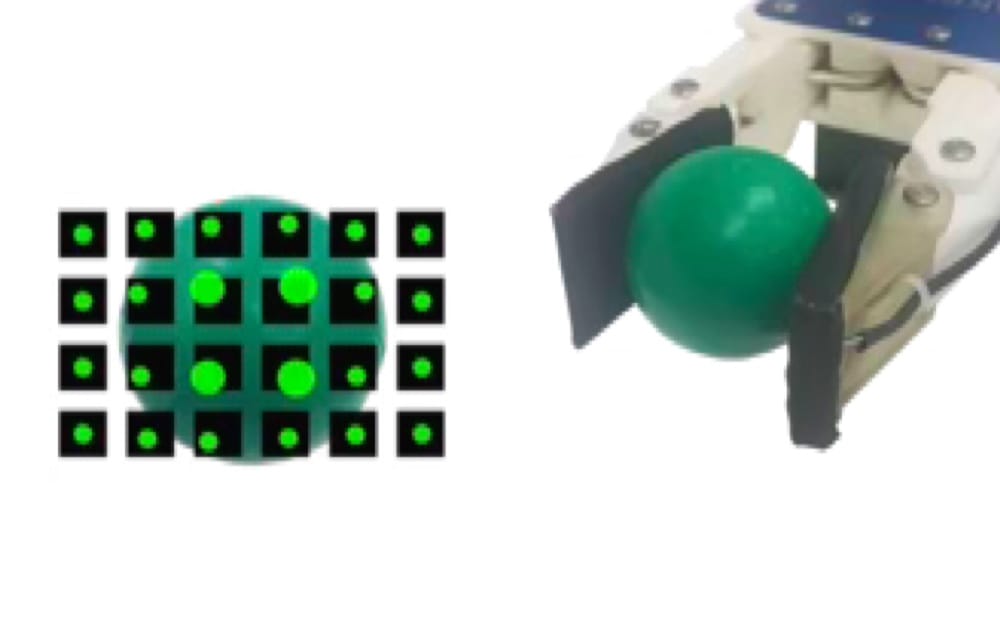
Sensitive: 0.1 gram-force Resolution
Soft & Robust
Minimal Wiring & Fast Sampling: 500 Hz
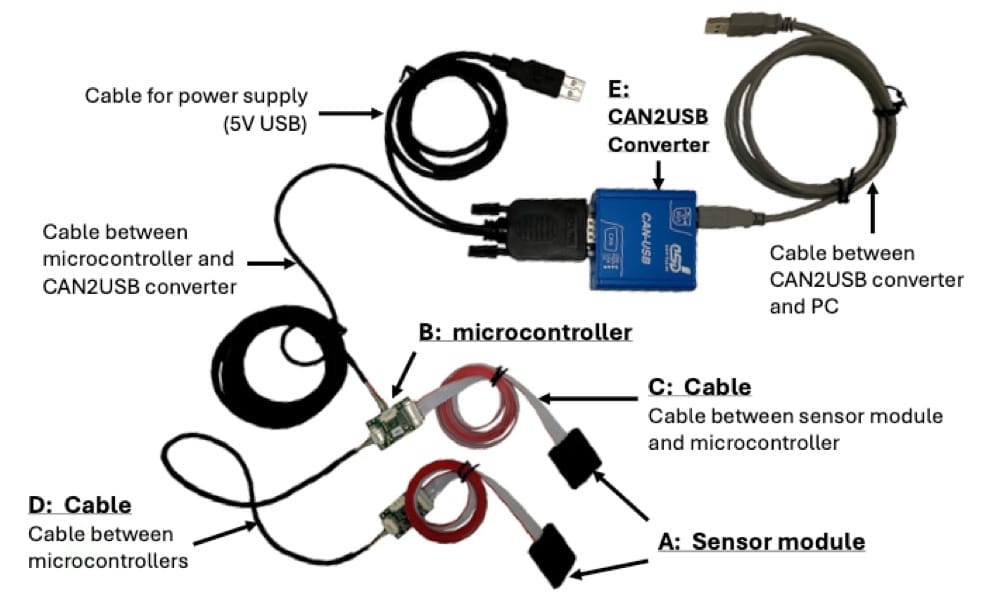
Easy to Integrate & Use
Calibrated in Newtons
Temperature & Magnetic Compensation
Process, visualize, and analyze tactile data with uAi software
XELA’s software platform for processing tactile data from uSkin sensors.